Ray forms of offsets and annuli: the level sets of their operands' values. More...
#include <cmath>#include <cstdint>#include <type_traits>#include "EBGeometry_AnalyticDistanceFunctions.hpp"#include "EBGeometry_AnalyticRayForms.hpp"#include "EBGeometry_BVHQuery.hpp"#include "EBGeometry_CSGRayForms.hpp"#include "EBGeometry_DCEL_Iterator.hpp"#include "EBGeometry_Fused.hpp"#include "EBGeometry_Math.hpp"#include "EBGeometry_MeshDistanceFunctions.hpp"#include "EBGeometry_MeshRayForms.hpp"#include "EBGeometry_Ray.hpp"#include "EBGeometry_RaySpans.hpp"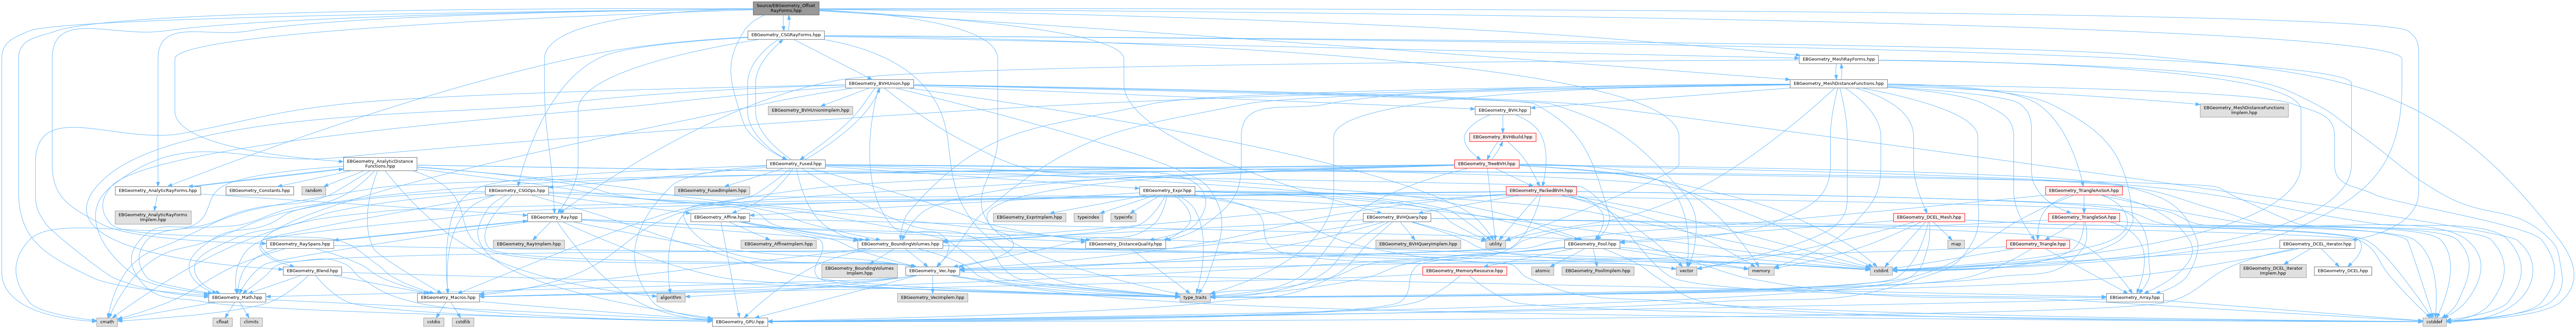
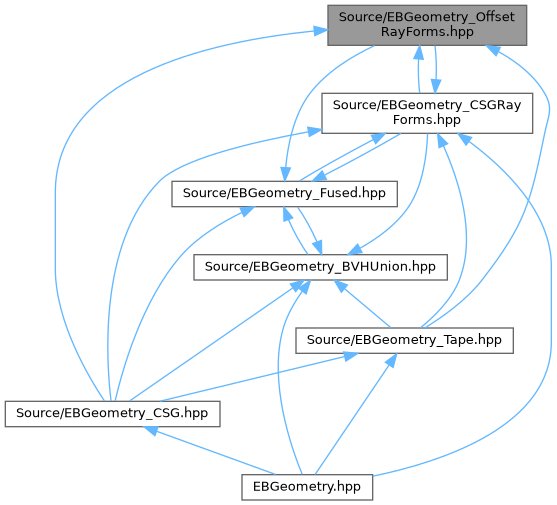
Go to the source code of this file.
Classes | |
| struct | EBGeometry::RayDetail::Piece< T > |
| Where a ray is inside a convex piece: [m_in, m_out], with the outward normals there; empty if m_in > m_out. More... | |
| struct | EBGeometry::RayDetail::GrownRayQuery< T > |
| A BVH ray query whose boxes are grown by a radius: what a mesh's offset faces are walked with. More... | |
| struct | EBGeometry::RayDetail::OffsetFaceUnion< T > |
| The union of the offset faces a ray meets, as disjoint spans merged as they come, at most Capacity: an offset face that would begin a span beyond them is dropped and lowers the horizon to its entry, which is also the walk's bound, so that the boxes beyond are left out. More... | |
| struct | EBGeometry::RayDetail::MeshFaces< S > |
| How a mesh's faces are walked along a ray, each given as its normal, a point in its plane, its edges, its squared distance from a point and its id. More... | |
| struct | EBGeometry::RayDetail::MeshFaces< TriMeshSDF< T, K, W > > |
| TriMeshSDF: its BVH, a triangle per SoA lane. More... | |
| struct | EBGeometry::RayDetail::MeshFaces< MeshSDF< T, K > > |
| MeshSDF: its BVH, a polygon face per leaf entry. More... | |
| struct | EBGeometry::RayDetail::MeshFaces< FlatMeshSDF< T > > |
| FlatMeshSDF: every face, in turn. More... | |
| struct | EBGeometry::RayDetail::NearestOffsetFace< T > |
| What a mesh's nearest offset-face walk finds. More... | |
| struct | EBGeometry::RayDetail::IsMeshLevel< S > |
| Whether a shape's level sets are a mesh's (its faces offset), or a fused affine map of one: costly to trace over a whole ray, cheap up to a first crossing. More... | |
| struct | EBGeometry::RayDetail::IsMeshLevel< TriMeshSDF< T, K, W > > |
| TriMeshSDF. More... | |
| struct | EBGeometry::RayDetail::IsMeshLevel< MeshSDF< T, K > > |
| MeshSDF. More... | |
| struct | EBGeometry::RayDetail::IsMeshLevel< FlatMeshSDF< T > > |
| FlatMeshSDF. More... | |
| struct | EBGeometry::RayDetail::IsMeshLevel< Fused::Node< Fused::AffineOp< T >, C > > |
| A fused affine map of one. More... | |
| struct | EBGeometry::RayDetail::DeferredOperand< Fused::Node< Fused::ShiftOp< T, IsAnnulus >, C >, std::enable_if_t< IsMeshLevel< C >::value > > |
| An intersection traces a fused offset or annulus of a mesh only within its other operands' spans, where it needs only first crossings: the nearest offset face, not the union of all along the ray. More... | |
| struct | EBGeometry::RayDetail::LevelForm< S, class > |
| A level set {f <= c} of a shape's value f along a ray. More... | |
| struct | EBGeometry::RayDetail::LevelForm< SphereSDF< T > > |
| A sphere's level set: the sphere of radius r + c. More... | |
| struct | EBGeometry::RayDetail::LevelForm< CapsuleSDF< T > > |
| A capsule's level set: the capsule of radius r + c. More... | |
| struct | EBGeometry::RayDetail::LevelForm< InfiniteCylinderSDF< T > > |
| An infinite cylinder's level set: the cylinder of radius r + c. More... | |
| struct | EBGeometry::RayDetail::LevelForm< PlaneSDF< T > > |
| A plane's level set: the half-space moved by c along the normal. More... | |
| struct | EBGeometry::RayDetail::LevelForm< BoxSDF< T > > |
| A box's level set: the box shrunk by -c, or grown by c into a rounded box. More... | |
| struct | EBGeometry::RayDetail::MeshLevelForm< S > |
| A mesh's level set: the mesh united with its faces offset by c, or less its faces offset by -c. More... | |
| struct | EBGeometry::RayDetail::LevelForm< TriMeshSDF< T, K, W > > |
| TriMeshSDF's level sets. More... | |
| struct | EBGeometry::RayDetail::LevelForm< MeshSDF< T, K > > |
| MeshSDF's level sets. More... | |
| struct | EBGeometry::RayDetail::LevelForm< FlatMeshSDF< T > > |
| FlatMeshSDF's level sets. More... | |
| struct | EBGeometry::RayDetail::HasLevelForm< S, class > |
| Whether a shape's level sets have a closed form (a LevelForm specialisation). More... | |
| struct | EBGeometry::RayDetail::HasLevelForm< S, std::void_t< decltype(LevelForm< S >::Convex)> > |
| A shape with a LevelForm. More... | |
| struct | EBGeometry::RayDetail::LevelForm< Fused::Node< Fused::AffineOp< T >, C >, std::enable_if_t< HasLevelForm< C >::value > > |
| A fused affine map's level sets: its operand's, at the level divided by the map's value scale, along the mapped ray. More... | |
| struct | EBGeometry::RayDetail::LevelView< S > |
| A level set of a shape, {f <= c}, or an annulus of it, {f <= c} less {f < -c}: a shape whose ray form traces it from the shape's closed-form level sets. More... | |
| struct | EBGeometry::RayDetail::IsComposition< LevelView< S > > |
| A level view is called out of line on a device where its shape is. More... | |
| struct | EBGeometry::RayForm< RayDetail::LevelView< S >, std::enable_if_t< RayDetail::HasLevelForm< S >::value > > |
| The ray form of a level view (RayDetail::LevelView): an offset or an annulus of a shape traced from its closed-form level sets, exactly and callable on a device. More... | |
| struct | EBGeometry::RayForm< Fused::Node< Fused::ShiftOp< T, IsAnnulus >, C >, std::enable_if_t< RayDetail::HasLevelForm< C >::value > > |
| The ray form of a fused offset or annulus of a shape whose level sets have a closed form (see RayDetail::LevelForm): traced through its level view. More... | |
Namespaces | |
| namespace | EBGeometry |
| Namespace containing all of EBGeometry's functionality. | |
Functions | |
| template<class T > | |
| Piece< T > | EBGeometry::RayDetail::ballPiece (const RayT< T > &a_ray, const Vec3T< T > &a_center, const T a_radius) noexcept |
| A ray through a ball. | |
| template<class T > | |
| Piece< T > | EBGeometry::RayDetail::tubePiece (const RayT< T > &a_ray, const Vec3T< T > &a_point, const Vec3T< T > &a_axis, const T a_radius) noexcept |
| A ray through an infinite cylinder: the points within a radius of a line. | |
| template<class T > | |
| Piece< T > | EBGeometry::RayDetail::capsulePiece (const RayT< T > &a_ray, const Vec3T< T > &a_a, const Vec3T< T > &a_b, const T a_radius) noexcept |
| A ray through a capsule: the segment [a, b] grown by a radius, the cylinder between the end planes united with the balls at the ends, which hold the end discs. | |
| template<class T > | |
| Piece< T > | EBGeometry::RayDetail::boxPiece (const RayT< T > &a_ray, const Vec3T< T > &a_lo, const Vec3T< T > &a_hi) noexcept |
| A ray through an axis-aligned box. | |
| template<class T > | |
| Piece< T > | EBGeometry::RayDetail::roundedBoxPiece (const RayT< T > &a_ray, const Vec3T< T > &a_lo, const Vec3T< T > &a_hi, const T a_radius) noexcept |
| A ray through a box grown by a radius: three boxes each grown along one axis, and a capsule along each of the twelve edges. | |
| template<class T , class Edges > | |
| T | EBGeometry::RayDetail::twiceArea (const Vec3T< T > &a_n, const Edges &a_edges) noexcept |
| Twice a planar polygon's signed area along its normal. | |
| template<class T , class Edges > | |
| bool | EBGeometry::RayDetail::offsetFaceEntry (const RayT< T > &a_ray, const Vec3T< T > &a_n, const Vec3T< T > &a_p0, const Edges &a_edges, const T a_radius, const T a_tMin, const T a_best, T &a_t, Vec3T< T > &a_normal, bool &a_inSlab) noexcept |
| Where a ray first enters a planar convex face offset by a radius, if before a bound: the offset face's flat side towards the ray first (where the ray enters the face's slab over the face), its rim (a capsule along each edge) only if that misses. | |
| template<class T , class Edges > | |
| Piece< T > | EBGeometry::RayDetail::offsetFacePiece (const RayT< T > &a_ray, const Vec3T< T > &a_n, const Vec3T< T > &a_p0, const Edges &a_edges, const T a_radius) noexcept |
| Where a ray is inside a planar convex face offset by a radius: its slab over the face, united with a capsule around each edge. | |
| template<class T , class S > | |
| NearestOffsetFace< T > | EBGeometry::RayDetail::nearestOffsetFace (const S &a_mesh, const RayT< T > &a_ray, const T a_tMin, const T a_tMax, const T a_radius) noexcept |
| The nearest entry after a_tMin of a mesh's faces offset by a radius, and whether one holds a_tMin. | |
| template<class T , class S > | |
| void | EBGeometry::RayDetail::offsetFaceUnion (const S &a_mesh, const RayT< T > &a_ray, const T a_tMin, const T a_tMax, const T a_radius, OffsetFaceUnion< T > &a_union) noexcept |
| The union of a mesh's faces offset by a radius along a ray, merged span by span. | |
| template<class T , class S > | |
| void | EBGeometry::RayDetail::meshSpans (const S &a_mesh, const RayT< T > &a_ray, const T a_tMin, const T a_tMax, const RayOptions< T > &a_options, const bool a_firstOnly, RaySpansT< T > &a_spans) noexcept |
| A mesh's own spans (RayDetail::shapeSpans()), out of line on a device, where its level sets need them: one copy of its walk per kernel. | |
| template<class T , class S > | |
| int | EBGeometry::RayDetail::convexLevelSpans (const LevelView< S > &a_view, const RayT< T > &a_ray, Piece< T >(&a_spans)[2]) noexcept |
| The spans of a convex level form's offset (one piece) or annulus (the outer piece less the inner, at most two), with the outward normals at their ends. | |
| template<class T > | |
| HitT< T > | EBGeometry::RayDetail::levelHitAt (const RayT< T > &a_ray, const T a_t, const Vec3T< T > &a_normal, const bool a_entering, const uint32_t a_primitive) |
| A crossing at a distance, with its normal, as a hit. | |
| template<class T , class S > | |
| Vec3T< T > | EBGeometry::RayDetail::levelNormal (const LevelView< S > &a_view, const Vec3T< T > &a_point, const T a_h) noexcept |
| A level view's outward normal at a point, from its shape's gradient (out of line already): reversed on an annulus's inner side, where the shape's value is negative. | |
| template<class T , class S > | |
| void | EBGeometry::RayDetail::levelSpans (const LevelView< S > &a_view, const RayT< T > &a_ray, const T a_tMin, const T a_tMax, const RayOptions< T > &a_options, const bool a_firstOnly, RaySpansT< T > &a_spans) noexcept |
| A level view's spans (its ray form's spans()), out of line on a device. | |
Detailed Description
Ray forms of offsets and annuli: the level sets of their operands' values.
An offset by r is the level set {f <= r} of its operand's value f, and an annulus of half-thickness d is {f <= d} less {f < -d}. Where the operand's level sets have a closed form, a ray traces them exactly instead of marching: a sphere's, a capsule's and an infinite cylinder's radius grows by the level, a plane moves, a box shrinks or grows into a rounded box, and a mesh's surface grown by d is the union of its faces offset by d (each face's slab over the face, with a capsule around each edge). The level passes through an affine map divided by the map's value scale. RayDetail::LevelView is such a level set of a shape. The fused Offset and Annular trace through it always; a tape's ray program traces its Annular and Offset clauses through it only when the tape lists TapeFeature::ExactOffsets, and marches them otherwise. An offset or annulus of anything else (a composition, CylinderSDF, whose grown rim is a torus, TorusSDF, or another offset or annulus) is marched.
Function Documentation
◆ ballPiece()
|
inlinenoexcept |
A ray through a ball.
Internal helper; not part of the public API. The discriminant is r^2 less the squared distance from the center to the ray, from the ray's nearest point: b^2 - |oc|^2 would lose the digits of a far origin.
- Template Parameters
-
T Floating-point precision.
- Parameters
-
[in] a_ray The ray, with a unit direction. [in] a_center Center. [in] a_radius Radius.
- Returns
- The piece.
◆ boxPiece()
|
inlinenoexcept |
A ray through an axis-aligned box.
Internal helper; not part of the public API.
- Template Parameters
-
T Floating-point precision.
- Parameters
-
[in] a_ray The ray. [in] a_lo Low corner. [in] a_hi High corner.
- Returns
- The piece, empty if the box is.
◆ capsulePiece()
|
inlinenoexcept |
A ray through a capsule: the segment [a, b] grown by a radius, the cylinder between the end planes united with the balls at the ends, which hold the end discs.
Internal helper; not part of the public API. Out of line on a device, as are roundedBoxPiece() and offsetFacePiece(): a rounded box tests twelve capsules and a face one per edge, and inlined in every tape kernel (through its leaf dispatch) they took ptxas several times as long.
- Template Parameters
-
T Floating-point precision.
- Parameters
-
[in] a_ray The ray, with a unit direction. [in] a_a One end. [in] a_b The other end. [in] a_radius Radius.
- Returns
- The piece.
◆ convexLevelSpans()
|
inlinenoexcept |
The spans of a convex level form's offset (one piece) or annulus (the outer piece less the inner, at most two), with the outward normals at their ends.
Internal helper; not part of the public API.
- Template Parameters
-
T Floating-point precision. S Shape type.
- Parameters
-
[in] a_view The view. [in] a_ray The ray. [out] a_spans The spans.
- Returns
- How many.
◆ levelHitAt()
|
inline |
A crossing at a distance, with its normal, as a hit.
Internal helper; not part of the public API.
- Template Parameters
-
T Floating-point precision.
- Parameters
-
[in] a_ray The ray. [in] a_t Distance. [in] a_normal Outward normal. [in] a_entering Whether the ray enters there. [in] a_primitive The primitive.
- Returns
- The hit.
◆ levelNormal()
|
inlinenoexcept |
A level view's outward normal at a point, from its shape's gradient (out of line already): reversed on an annulus's inner side, where the shape's value is negative.
Internal helper; not part of the public API. Where a crossing's own normal is not found (see levelLeafHit()); the view's own value would bring another copy of a mesh's distance into a kernel.
- Template Parameters
-
T Floating-point precision. S Shape type.
- Parameters
-
[in] a_view The view. [in] a_point The point. [in] a_h Finite-difference step.
- Returns
- The normal.
◆ levelSpans()
|
inlinenoexcept |
A level view's spans (its ray form's spans()), out of line on a device.
Internal helper; not part of the public API. What a tape's leaf dispatch and a fused offset or annulus call: inlined, every call site copied a mesh's offset-face walks and a box's rounded edges, and ptxas took several times as long and as much memory on a tape kernel.
- Template Parameters
-
T Floating-point precision. S Shape type.
- Parameters
-
[in] a_view The view. [in] a_ray The ray. [in] a_tMin Start. [in] a_tMax End. [in] a_options How to march. [in] a_firstOnly Whether only the first crossing is needed. [out] a_spans The list.
◆ meshSpans()
|
inlinenoexcept |
A mesh's own spans (RayDetail::shapeSpans()), out of line on a device, where its level sets need them: one copy of its walk per kernel.
Internal helper; not part of the public API.
- Template Parameters
-
T Floating-point precision. S Mesh type.
- Parameters
-
[in] a_mesh The mesh. [in] a_ray The ray. [in] a_tMin Start. [in] a_tMax End. [in] a_options How to march. [in] a_firstOnly Whether only the first crossing is needed. [out] a_spans The list.
◆ nearestOffsetFace()
|
inlinenoexcept |
The nearest entry after a_tMin of a mesh's faces offset by a radius, and whether one holds a_tMin.
Internal helper; not part of the public API. Out of line on a device, like every mesh trace.
- Template Parameters
-
T Floating-point precision. S Mesh type.
- Parameters
-
[in] a_mesh The mesh. [in] a_ray The ray. [in] a_tMin Start. [in] a_tMax End. [in] a_radius Radius, positive.
- Returns
- What the walk found.
◆ offsetFaceEntry()
|
inlinenoexcept |
Where a ray first enters a planar convex face offset by a radius, if before a bound: the offset face's flat side towards the ray first (where the ray enters the face's slab over the face), its rim (a capsule along each edge) only if that misses.
Internal helper; not part of the public API. The offset face lies in the slab |n . (x - p0)| <= radius, so a ray outside the slab over [a_tMin, a_best] does not enter it there, and nothing of it is entered before the slab. A ray whose part in the slab lies further than the radius outside one edge's line passes the face by more than the radius. The rest test each edge's capsule if the ray passes within the radius of the edge's line.
- Template Parameters
-
T Floating-point precision. Edges Calls its argument with each edge's ends, in order around the face.
- Parameters
-
[in] a_ray The ray. [in] a_n Unit normal, zero for a face of no area. [in] a_p0 A point in the face's plane. [in] a_edges The edges. [in] a_radius Radius, positive. [in] a_tMin Start. [in] a_best Entries at or beyond it are not wanted. [out] a_t The entry. [out] a_normal Its outward normal. [out] a_inSlab Whether a_tMin is in the slab (the ray may start inside the offset face).
- Returns
- Whether an entry in [a_tMin, a_best) was found.
◆ offsetFacePiece()
|
inlinenoexcept |
Where a ray is inside a planar convex face offset by a radius: its slab over the face, united with a capsule around each edge.
Internal helper; not part of the public API.
- Template Parameters
-
T Floating-point precision. Edges Calls its argument with each edge's ends, in order around the face.
- Parameters
-
[in] a_ray The ray. [in] a_n Unit normal, zero for a face of no area. [in] a_p0 A point in the face's plane. [in] a_edges The edges. [in] a_radius Radius, positive.
- Returns
- The piece.
◆ offsetFaceUnion()
|
inlinenoexcept |
The union of a mesh's faces offset by a radius along a ray, merged span by span.
Internal helper; not part of the public API. Out of line on a device, like every mesh trace.
- Template Parameters
-
T Floating-point precision. S Mesh type.
- Parameters
-
[in] a_mesh The mesh. [in] a_ray The ray. [in] a_tMin Start. [in] a_tMax End. [in] a_radius Radius, positive. [out] a_union The merged spans, with the normals at their exits.
◆ roundedBoxPiece()
|
inlinenoexcept |
A ray through a box grown by a radius: three boxes each grown along one axis, and a capsule along each of the twelve edges.
Internal helper; not part of the public API.
- Template Parameters
-
T Floating-point precision.
- Parameters
-
[in] a_ray The ray. [in] a_lo Low corner. [in] a_hi High corner. [in] a_radius Radius, positive.
- Returns
- The piece.
◆ tubePiece()
|
inlinenoexcept |
A ray through an infinite cylinder: the points within a radius of a line.
Internal helper; not part of the public API. The discriminant is taken as for a ball.
- Template Parameters
-
T Floating-point precision.
- Parameters
-
[in] a_ray The ray, with a unit direction. [in] a_point A point on the line. [in] a_axis The line's direction, unit length. [in] a_radius Radius.
- Returns
- The piece.
◆ twiceArea()
|
inlinenoexcept |
Twice a planar polygon's signed area along its normal.
Internal helper; not part of the public API. Its sign says whether the edges run counter-clockwise about the normal (positive), which sets which side of each edge is inside.
- Template Parameters
-
T Floating-point precision. Edges Calls its argument with each edge's ends, in order around the polygon.
- Parameters
-
[in] a_n Unit normal. [in] a_edges The edges.
- Returns
- The area.
