A FlatMeshSDF must be trivially copyable: that is what lets a rebasedView() be byte-copied into a device address space with no pointer patching. More...
#include <EBGeometry_MeshDistanceFunctions.hpp>
Classes | |
| struct | Layout |
| The object's arrays as offsets into its pool, with no location (see PoolHandle). More... | |
Public Types | |
| using | Face = typename EBGeometry::DCEL::FaceT< T > |
| Alias for DCEL face type. | |
| using | Mesh = typename EBGeometry::DCEL::MeshT< T > |
| Alias for DCEL mesh type. | |
| using | Root = EBGeometry::BVH::PackedBVH< T, uint32_t, K > |
| Alias for the linearized BVH root. Its primitives are face ids. | |
| using | Node = typename Root::Node |
| Alias for a single linearized node. | |
Public Member Functions | |
| MeshSDF ()=delete | |
| Default disallowed constructor. | |
| MeshSDF (const Layout &a_layout, const PoolLocation &a_location) noexcept | |
| Rebuild a handle from a stored layout and the location of the pool that holds it. | |
| Layout | layout () const noexcept |
| The object's arrays without its location, for storing it inside another pool-resident object. | |
| MeshSDF (const Mesh &a_mesh, Pool &a_pool, const BVH::Construction a_construction) | |
| Full constructor. Copies the mesh descriptor and builds the BVH over its faces. | |
| MeshSDF (const Mesh &a_mesh, Pool &a_pool, const BVH::Construction a_construction, const BVH::ConstructionOptions &a_options) | |
| Full constructor with leaf-size settings. | |
| T | signedDistance (const Vec3T< T > &a_point) const noexcept |
| Compute the signed distance from a_point to the mesh. | |
| ClosestFace< T > | getClosestFace (const Vec3T< T > &a_point) const noexcept |
| Find the face closest to a_point, and the signed distance to it. | |
| Root | getRoot () const noexcept |
| Get the PackedBVH enclosing the mesh. | |
| Mesh | getMesh () const noexcept |
| Get the DCEL mesh descriptor the BVH's faces resolve against. | |
| EBGeometry::BoundingVolumes::AABBT< T > | computeBoundingVolume () const noexcept |
| Compute the AABB enclosing the entire mesh. | |
| MeshSDF | rebasedView (const Pool &a_pool) const noexcept |
Produce a copy of this object that resolves against a_pool. | |
| MeshSDF | deepCopy (Pool &a_dstPool) const |
Duplicate the mesh's and the BVH's storage into a_dstPool. | |
 Public Member Functions inherited from EBGeometry::PoolHandle | |
| PoolLocation | location () const noexcept |
| Where this handle's arrays live. | |
| bool | isAttachedTo (const Pool &a_pool) const noexcept |
Check whether this handle's arrays were reserved from a_pool. | |
Static Public Member Functions | |
| static BVH::ConstructionOptions | defaultConstructionOptions () noexcept |
| The leaf-size settings the constructor without options uses. | |
Static Public Attributes | |
| static constexpr DistanceQuality | distanceQuality = DistanceQuality::Exact |
| How far signedDistance() can be trusted as a distance: the Euclidean distance to a watertight mesh. | |
Additional Inherited Members | |
| Protected Member Functions inherited from EBGeometry::PoolHandle | |
| PoolHandle () noexcept=default | |
| An unset location; the first reservation attaches it. | |
| PoolHandle (const PoolLocation &a_location) noexcept | |
| Adopt a location, as a handle rebuilt from a stored layout does. | |
| PoolHandle (const PoolHandle &) noexcept=default | |
| Copy a handle, as a derived handle's copy does. | |
| PoolHandle (PoolHandle &&) noexcept=default | |
| Move a handle; the same as a copy. | |
| PoolHandle & | operator= (const PoolHandle &) noexcept=default |
| Copy-assign a handle, as a derived handle's assignment does. | |
| PoolHandle & | operator= (PoolHandle &&) noexcept=default |
| Move-assign a handle; the same as a copy. | |
| ~PoolHandle () noexcept=default | |
| Destructor; protected, since a PoolHandle exists only as the base of a handle. | |
| void * | base () noexcept |
| The base address this handle's offsets resolve against; see PoolLocation::base(). | |
| const void * | base () const noexcept |
| The base address this handle's offsets resolve against, for read-only access. | |
| void | attach (const Pool &a_pool, const char *a_who) noexcept |
Follow a_pool, as the first reservation does; see PoolLocation::attach(). | |
| PoolLocation | rebasedLocation (const Pool &a_pool, uint64_t a_endByte, const char *a_who) const noexcept |
| The location of this handle's arrays in another pool of its mirror chain; see PoolLocation::rebasedOnto(). | |
| void | setLocation (const PoolLocation &a_location) noexcept |
| Replace the location, for a view or a copy made by a derived handle. | |
Detailed Description
class EBGeometry::MeshSDF< T, K >
A FlatMeshSDF must be trivially copyable: that is what lets a rebasedView() be byte-copied into a device address space with no pointer patching.
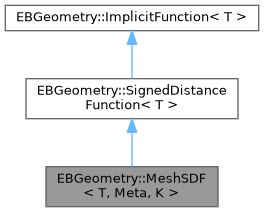
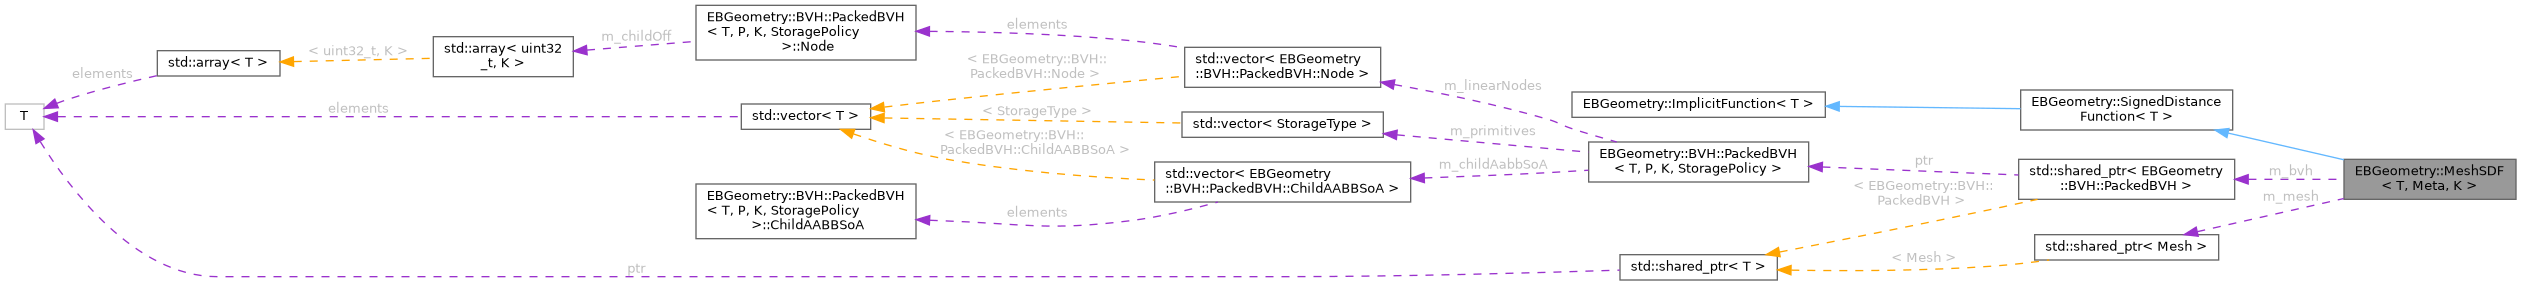
Signed distance function for a DCEL mesh, accelerated by a PackedBVH over its faces. Accepts any polygon, not just triangles.
The BVH's primitives are face ids: indices into the mesh's face array, four bytes each. Every query resolves a face through the mesh, which MeshSDF holds as well, so the mesh is the only copy of the geometry: flipping the mesh (DCEL::MeshT::flip()) after building flips every distance, and after moving vertices, reconciling the mesh and refitting the BVH (see getRoot()) is enough. The price of four bytes per face rather than the 88 of a face copy is reading faces in mesh order rather than leaf order, which made queries on the armadillo (100k faces) about 15% slower than with copies, near the surface and away from it alike. SIMD node pruning is used when T and K match an available ISA path.
A plain value type, like FlatMeshSDF: it holds the mesh descriptor and the BVH by value, both resolving against the one Pool passed to the constructor, so it is trivially copyable and signedDistance() is callable on the host and on a device. It has no virtual functions: a class with them can never be passed to a kernel. Copies share the pool memory, and the pool must outlive all of them. To evaluate on a device, freeze and mirror the pool and pass rebasedView() into a kernel.
- Template Parameters
-
T Floating-point precision type (float or double). K BVH branching factor (number of children per internal node).
Constructor & Destructor Documentation
◆ MeshSDF() [1/3]
|
inlinenoexcept |
Rebuild a handle from a stored layout and the location of the pool that holds it.
How an outer pool-resident object, such as a BVHUnion, evaluates a MeshSDF it stores as a layout. a_location must belong to the pool the layout was reserved from, or to a mirror of it; nothing is checked, since a device has no pool to check against.
- Parameters
-
[in] a_layout The arrays. [in] a_location Where they live.
◆ MeshSDF() [2/3]
|
inline |
Full constructor. Copies the mesh descriptor and builds the BVH over its faces.
No default arguments: this is a low-level constructor, and callers working at this level must consciously choose a construction method. Use Parser::readIntoMeshSDF for sensible defaults. The BVH is reserved from a_pool, which must be the pool a_mesh was built in, so that one rebasedView() rebases both. a_pool must outlive this object and every copy of it.
- Parameters
-
[in] a_mesh Input mesh, built against a_pool. [in,out] a_pool Pool a_mesh's storage was reserved from; the BVH is reserved here too. [in] a_construction Preset construction method; every BVH::Construction value is supported. SAH (binned Surface Area Heuristic) is recommended. The leaf sizes are defaultConstructionOptions(): the top-down methods stop at fewer than K faces per leaf, and ClusterSAH uses the default ClusterSpec, so a leaf holds up to (K-1) clusters of faces.
◆ MeshSDF() [3/3]
|
inline |
Full constructor with leaf-size settings.
As the constructor without options, which uses defaultConstructionOptions(). The chosen method reads only its own field of a_options; see BVH::ConstructionOptions.
- Parameters
-
[in] a_mesh Input mesh, built against a_pool. [in,out] a_pool Pool a_mesh's storage was reserved from; the BVH is reserved here too. [in] a_construction Preset construction method; every BVH::Construction value is supported. [in] a_options Leaf-size settings, in faces.
Member Function Documentation
◆ computeBoundingVolume()
|
inlinenoexcept |
Compute the AABB enclosing the entire mesh.
- Returns
- Axis-aligned bounding box of the mesh.
◆ deepCopy()
|
inline |
Duplicate the mesh's and the BVH's storage into a_dstPool.
The copy constructor copies descriptors only. This gives genuinely independent storage. The copied face ids still name the right faces of the copied mesh, since a mesh deep copy preserves every element's index.
- Parameters
-
[in,out] a_dstPool Pool to reserve the copy from; may be this object's own pool.
◆ defaultConstructionOptions()
|
inlinestaticnoexcept |
The leaf-size settings the constructor without options uses.
K-1 faces per leaf for the top-down methods (a node with fewer than K faces is a leaf), a target of 1 for the space-filling curves (the deepest balanced tree, at most K faces per leaf), and the default ClusterSpec for ClusterSAH. Start from these to change one method's setting; see BVH::ConstructionOptions.
- Returns
- The default settings.
◆ getClosestFace()
|
inlinenoexcept |
Find the face closest to a_point, and the signed distance to it.
The same BVH traversal as signedDistance() (PackedBVH::traverse() with a PointQuery), keeping the winning face's id as well, so it is callable on a device too.
- Parameters
-
[in] a_point Query point. Must be finite.
- Returns
- The closest face's id (its index in the mesh) and signed distance. The signed distance equals what signedDistance() returns for the same point.
◆ getMesh()
|
inlinenoexcept |
◆ getRoot()
|
inlinenoexcept |
Get the PackedBVH enclosing the mesh.
Mutable, so that PackedBVH::refit() can be called on it. After moving the mesh's vertices, reconcile the mesh (DCEL::MeshT::reconcile()), which recomputes its normals, then refit with each face's new bounding box:
This is enough because the BVH stores face ids and reads the faces from the mesh. A deformation large enough to degrade the tree still calls for a rebuild.
- Returns
- The packed BVH.
◆ layout()
|
inlinenoexcept |
The object's arrays without its location, for storing it inside another pool-resident object.
- Returns
- The layout.
◆ rebasedView()
|
inlinenoexcept |
Produce a copy of this object that resolves against a_pool.
Rebases the mesh descriptor and the BVH together; see DCEL::MeshT::rebasedView() and BVH::PackedBVH::rebasedView() for the contract. This is the one sanctioned crossing to a device.
- Parameters
-
[in] a_pool Pool to rebase onto: the object's own pool or one in its mirror chain.
- Returns
- A MeshSDF resolving against
a_pool.
◆ signedDistance()
|
inlinenoexcept |
Compute the signed distance from a_point to the mesh.
- Parameters
-
[in] a_point Query point.
- Returns
- Signed distance to the nearest face; negative inside the mesh.
The documentation for this class was generated from the following file:
