Signed distance function for a pure triangle mesh using SoA-grouped primitives in a compact (linearized) BVH. More...
#include <EBGeometry_MeshDistanceFunctions.hpp>
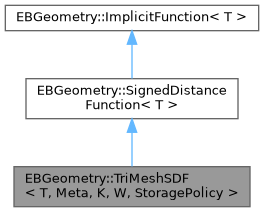
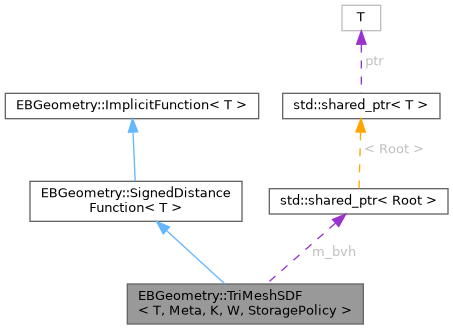
Classes | |
| struct | Layout |
| The object's arrays as offsets into its pool, with no location (see PoolHandle). More... | |
Public Types | |
| using | Mesh = EBGeometry::DCEL::MeshT< T > |
| Alias for DCEL mesh type. | |
| using | Tri = typename EBGeometry::Triangle< T > |
| Alias for the flat triangle type the BVH is built from. | |
| using | TriAoSoA = TriangleAoSoA< T, W > |
| Alias for the face-id-carrying SoA triangle group type (the BVH leaf primitive). | |
| using | Root = typename EBGeometry::BVH::PackedBVH< T, TriAoSoA, K > |
| Alias for which BVH root node. | |
Public Member Functions | |
| TriMeshSDF ()=delete | |
| Default disallowed constructor. | |
| TriMeshSDF (const Layout &a_layout, const PoolLocation &a_location) noexcept | |
| Rebuild a handle from a stored layout and the location of the pool that holds it. | |
| Layout | layout () const noexcept |
| The object's arrays without its location, for storing it inside another pool-resident object. | |
| TriMeshSDF (const Mesh &a_mesh, Pool &a_pool, const BVH::Construction a_construction, const size_t a_maxLeafGroups) | |
| Full constructor. Extracts flat triangles from a DCEL mesh, then builds the BVH. | |
| TriMeshSDF (const std::vector< Tri > &a_triangles, Pool &a_pool, const BVH::Construction a_construction, const size_t a_maxLeafGroups) | |
| Full constructor. Takes the input triangles and creates the BVH. | |
| TriMeshSDF (const Mesh &a_mesh, Pool &a_pool, const BVH::Construction a_construction, const BVH::ConstructionOptions &a_options) | |
| Full constructor from a DCEL mesh, with leaf-size settings. | |
| TriMeshSDF (const std::vector< Tri > &a_triangles, Pool &a_pool, const BVH::Construction a_construction, const BVH::ConstructionOptions &a_options) | |
| Full constructor from a triangle soup, with leaf-size settings. | |
| T | signedDistance (const Vec3T< T > &a_point) const noexcept |
| Compute the signed distance from a_point to the triangle mesh. | |
| ClosestFace< T > | getClosestFace (const Vec3T< T > &a_point) const noexcept |
| Find the face closest to a_point, and the signed distance to it. | |
| Root | getRoot () const noexcept |
| Get the PackedBVH storing SoA triangle groups. | |
| EBGeometry::BoundingVolumes::AABBT< T > | computeBoundingVolume () const noexcept |
| Compute the AABB enclosing the entire triangle mesh. | |
| TriMeshSDF | rebasedView (const Pool &a_pool) const noexcept |
Produce a copy of this object that resolves against a_pool. | |
| TriMeshSDF | deepCopy (Pool &a_dstPool) const |
Duplicate the BVH's storage into a_dstPool. | |
 Public Member Functions inherited from EBGeometry::PoolHandle | |
| PoolLocation | location () const noexcept |
| Where this handle's arrays live. | |
| bool | isAttachedTo (const Pool &a_pool) const noexcept |
Check whether this handle's arrays were reserved from a_pool. | |
Static Public Member Functions | |
| static BVH::ConstructionOptions | defaultConstructionOptions (const size_t a_maxLeafGroups) noexcept |
| The leaf-size settings the constructors taking a_maxLeafGroups use. | |
Static Public Attributes | |
| static constexpr DistanceQuality | distanceQuality = DistanceQuality::Exact |
| How far signedDistance() can be trusted as a distance: the Euclidean distance to a watertight mesh. | |
Additional Inherited Members | |
| Protected Member Functions inherited from EBGeometry::PoolHandle | |
| PoolHandle () noexcept=default | |
| An unset location; the first reservation attaches it. | |
| PoolHandle (const PoolLocation &a_location) noexcept | |
| Adopt a location, as a handle rebuilt from a stored layout does. | |
| PoolHandle (const PoolHandle &) noexcept=default | |
| Copy a handle, as a derived handle's copy does. | |
| PoolHandle (PoolHandle &&) noexcept=default | |
| Move a handle; the same as a copy. | |
| PoolHandle & | operator= (const PoolHandle &) noexcept=default |
| Copy-assign a handle, as a derived handle's assignment does. | |
| PoolHandle & | operator= (PoolHandle &&) noexcept=default |
| Move-assign a handle; the same as a copy. | |
| ~PoolHandle () noexcept=default | |
| Destructor; protected, since a PoolHandle exists only as the base of a handle. | |
| void * | base () noexcept |
| The base address this handle's offsets resolve against; see PoolLocation::base(). | |
| const void * | base () const noexcept |
| The base address this handle's offsets resolve against, for read-only access. | |
| void | attach (const Pool &a_pool, const char *a_who) noexcept |
Follow a_pool, as the first reservation does; see PoolLocation::attach(). | |
| PoolLocation | rebasedLocation (const Pool &a_pool, uint64_t a_endByte, const char *a_who) const noexcept |
| The location of this handle's arrays in another pool of its mirror chain; see PoolLocation::rebasedOnto(). | |
| void | setLocation (const PoolLocation &a_location) noexcept |
| Replace the location, for a view or a copy made by a derived handle. | |
Detailed Description
class EBGeometry::TriMeshSDF< T, K, W >
Signed distance function for a pure triangle mesh using SoA-grouped primitives in a compact (linearized) BVH.
Triangles are packed into SoA groups of W triangles each (TriangleAoSoA<T,W>), enabling SIMD evaluation of up to W signed distances simultaneously.
No default arguments: this is a low-level constructor, and callers who excavate down to it must consciously choose K and W. BVH::DefaultBranchingRatio<T>() and TriangleSoA::DefaultWidth<T>() (both 4) are the portable choice, and Parser::readIntoTriMeshSDF's defaults.
Each leaf primitive is a TriangleAoSoA<T, W>: an SoA triangle block for SIMD signed-distance evaluation, plus a physically separate per-lane array of face ids, the index of the mesh face each triangle was cut from. The hot signedDistance() path never reads the ids; getClosestFace() does, returning the closest triangle's signed distance together with its face id. The groups are self-contained – no reference back to a mesh – so the packed BVH is the only thing this class holds, and a mesh changed after the build is not seen.
A plain value type, like FlatMeshSDF and MeshSDF: the BVH is held by value in the Pool passed to the constructor, so the class is trivially copyable and every query is callable on the host and on a device. It has no virtual functions. Copies share the pool memory, and the pool must outlive all of them. To evaluate on a device, freeze and mirror the pool and pass rebasedView() into a kernel.
Constructor & Destructor Documentation
◆ TriMeshSDF() [1/5]
|
inlinenoexcept |
Rebuild a handle from a stored layout and the location of the pool that holds it.
How an outer pool-resident object, such as a BVHUnion, evaluates a TriMeshSDF it stores as a layout. a_location must belong to the pool the layout was reserved from, or to a mirror of it; nothing is checked, since a device has no pool to check against.
- Parameters
-
[in] a_layout The arrays. [in] a_location Where they live.
◆ TriMeshSDF() [2/5]
|
inline |
Full constructor. Extracts flat triangles from a DCEL mesh, then builds the BVH.
No default arguments: this is a low-level constructor, and callers who excavate down to it must consciously choose every parameter. Use Parser::readIntoTriMeshSDF for sensible defaults. The mesh is not retained: its triangles are copied into the BVH's SoA groups, each carrying the id of the face it was cut from.
- Parameters
-
[in] a_mesh DCEL mesh. Faces with more than three vertices are fan-triangulated. [in,out] a_pool Pool the packed BVH is reserved from; must outlive this object. [in] a_construction Preset construction method; every BVH::Construction value is supported. SAH (binned Surface Area Heuristic) produces near-optimal traversal cost; CentroidSplit and MidpointSplit are faster to build but yield deeper trees. Every method honours a_maxLeafGroups through defaultConstructionOptions(): the top-down methods as a bound, the space-filling curves as a target, and ClusterSAH through its cluster size. [in] a_maxLeafGroups Maximum number of full W-sized TriangleSoA groups per BVH leaf; the actual raw-triangle leaf-size bound used is a_maxLeafGroups * W. This bounds the pre-packing tree's leaf size, not the packed representation directly: each leaf's triangles become their own TriangleSoA group(s) during packing, with no batching across leaves, so a leaf smaller than W wastes some of its group's SIMD lanes on padding. For the top-down methods it is an upper bound, not a target — the partitioner still splits down to tighter, more selective leaves wherever the geometry warrants it; the space-filling curves aim for it. Expressing this as a count of W-sized groups (rather than a raw triangle count) makes it impossible to accidentally pick a leaf size that isn't a multiple of W. Must be > 0.
◆ TriMeshSDF() [3/5]
|
inline |
Full constructor. Takes the input triangles and creates the BVH.
- Parameters
-
[in] a_triangles Input triangle soup; copied into the BVH's SoA groups. getClosestFace() reports the face id each triangle carries (Triangle::getFaceId()). [in,out] a_pool Pool the packed BVH is reserved from; must outlive this object. [in] a_construction Preset BVH construction method (see the mesh-based constructor for details). [in] a_maxLeafGroups Maximum number of full W-sized TriangleSoA groups per BVH leaf (see the mesh-based constructor for the tree-quality/SIMD-occupancy trade-off). Must be > 0.
◆ TriMeshSDF() [4/5]
|
inline |
Full constructor from a DCEL mesh, with leaf-size settings.
As the constructor taking a_maxLeafGroups, which uses defaultConstructionOptions(a_maxLeafGroups). The chosen method reads only its own field of a_options, counted in triangles; see BVH::ConstructionOptions. A leaf's triangles are packed into ceil(n / W) groups.
- Parameters
-
[in] a_mesh DCEL mesh. Faces with more than three vertices are fan-triangulated. [in,out] a_pool Pool the packed BVH is reserved from; must outlive this object. [in] a_construction Preset construction method; every BVH::Construction value is supported. [in] a_options Leaf-size settings, in triangles.
◆ TriMeshSDF() [5/5]
|
inline |
Full constructor from a triangle soup, with leaf-size settings.
- Parameters
-
[in] a_triangles Input triangle soup; copied into the BVH's SoA groups. [in,out] a_pool Pool the packed BVH is reserved from; must outlive this object. [in] a_construction Preset construction method; every BVH::Construction value is supported. [in] a_options Leaf-size settings, in triangles; see the mesh-based constructor.
Member Function Documentation
◆ computeBoundingVolume()
|
inlinenoexcept |
Compute the AABB enclosing the entire triangle mesh.
- Returns
- Axis-aligned bounding box of the mesh.
◆ deepCopy()
|
inline |
Duplicate the BVH's storage into a_dstPool.
The copy constructor copies descriptors only. This gives genuinely independent storage.
- Parameters
-
[in,out] a_dstPool Pool to reserve the copy from; may be this object's own pool.
- Returns
- A TriMeshSDF over an independent copy of the BVH, attached to
a_dstPool.
◆ defaultConstructionOptions()
|
inlinestaticnoexcept |
The leaf-size settings the constructors taking a_maxLeafGroups use.
At most a_maxLeafGroups * W triangles per leaf for the top-down methods, the same as the target for the space-filling curves, and for ClusterSAH a cluster size that keeps a leaf of K-1 clusters within that bound (or within K-1 triangles, if the bound is smaller, since a cluster holds at least one). Start from these to change one method's setting; see BVH::ConstructionOptions.
- Parameters
-
[in] a_maxLeafGroups Maximum number of full W-sized TriangleSoA groups per leaf. Must be > 0.
- Returns
- The settings, in triangles.
◆ getClosestFace()
|
inlinenoexcept |
Find the face closest to a_point, and the signed distance to it.
The face-id-retrieving companion to signedDistance(): it drives the same SIMD-pruned BVH traversal (PackedBVH::traverse() with a PointQuery), but each visited leaf group reports the winning triangle's face id via TriangleAoSoA::signedDistance(point, uint32_t&).
- Parameters
-
[in] a_point Query point. Must be finite.
- Returns
- The face id of the closest triangle and the signed distance to it. The signed distance agrees with what signedDistance() returns for the same point except where two triangles are equally near to rounding: on the host, signedDistance() ranks triangles by squared unsigned distance and signs only the winner, while this function ranks them by the absolute value of their signed distances.
◆ getRoot()
|
inlinenoexcept |
Get the PackedBVH storing SoA triangle groups.
- Returns
- The packed BVH.
◆ layout()
|
inlinenoexcept |
The object's arrays without its location, for storing it inside another pool-resident object.
- Returns
- The layout.
◆ rebasedView()
|
inlinenoexcept |
Produce a copy of this object that resolves against a_pool.
Rebases the BVH; see BVH::PackedBVH::rebasedView() for the contract. This is the one sanctioned crossing to a device.
- Parameters
-
[in] a_pool Pool to rebase onto: the object's own pool or one in its mirror chain.
- Returns
- A TriMeshSDF resolving against
a_pool.
◆ signedDistance()
|
inlinenoexcept |
Compute the signed distance from a_point to the triangle mesh.
- Parameters
-
[in] a_point Query point.
- Returns
- Signed distance to the nearest triangle; negative inside the mesh.
The documentation for this class was generated from the following file:
