Three-dimensional vector class with arithmetic operators. More...
#include <EBGeometry_Vec.hpp>
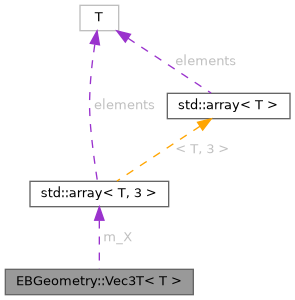
Public Member Functions | |
| Vec3T () noexcept=default | |
| Default constructor. Leaves the components uninitialized. | |
| constexpr | Vec3T (const Vec3T< T > &a_u) noexcept=default |
| Copy constructor. | |
| constexpr | Vec3T (const T &a_x, const T &a_y, const T &a_z) noexcept |
| Full constructor. | |
| ~Vec3T () noexcept=default | |
| Destructor (does nothing) | |
| constexpr bool | lessLX (const Vec3T< T > &u) const noexcept |
| Lexicographic comparison (x first, then y, then z). | |
| constexpr T & | operator[] (size_t i) noexcept |
| Mutable element access. | |
| constexpr const T & | operator[] (size_t i) const noexcept |
| Const element access. | |
| constexpr bool | operator== (const Vec3T< T > &u) const noexcept |
| Equality comparison. | |
| constexpr bool | operator!= (const Vec3T< T > &u) const noexcept |
| Inequality comparison. | |
| constexpr Vec3T< T > & | operator= (const Vec3T< T > &u) noexcept=default |
| Assignment operator. | |
| constexpr Vec3T< T > | operator+ (const Vec3T< T > &u) const noexcept |
| Addition operator. | |
| constexpr Vec3T< T > | operator- (const Vec3T< T > &u) const noexcept |
| Subtraction operator. Returns a new vector with subtracted components. | |
| constexpr Vec3T< T > | operator+ () const noexcept |
| Identity operator. | |
| constexpr Vec3T< T > | operator- () const noexcept |
| Negation operator. | |
| constexpr Vec3T< T > | operator* (const T &s) const noexcept |
| Multiplication operator. Returns a vector with scalar multiplied components. | |
| constexpr Vec3T< T > | operator* (const Vec3T< T > &s) const noexcept |
| Component-wise multiplication operator. | |
| constexpr Vec3T< T > | operator/ (const T &s) const noexcept |
| Division operator. Returns a vector with scalar divided components. | |
| constexpr Vec3T< T > | operator/ (const Vec3T< T > &v) const noexcept |
| Component-wise division operator. | |
| constexpr Vec3T< T > & | operator+= (const Vec3T< T > &u) noexcept |
| Vector addition operator. | |
| constexpr Vec3T< T > & | operator-= (const Vec3T< T > &u) noexcept |
| Vector subtraction operator. | |
| constexpr Vec3T< T > & | operator*= (const T &s) noexcept |
| Vector multiplication operator. | |
| constexpr Vec3T< T > & | operator/= (const T &s) noexcept |
| In-place scalar division operator. | |
| constexpr Vec3T< T > | cross (const Vec3T< T > &u) const noexcept |
| Vector cross product. | |
| constexpr T | dot (const Vec3T< T > &u) const noexcept |
| Vector dot product. | |
| size_t | minDir (const bool a_doAbs) const noexcept |
| Return the index of the smallest component (optionally by magnitude). | |
| size_t | maxDir (const bool a_doAbs) const noexcept |
| Return the direction which has the largest component (can be absolute) | |
| T | length () const noexcept |
| Compute vector length. | |
| constexpr T | length2 () const noexcept |
| Compute squared vector length. | |
Deleted ordering operators | |
Vec3T has no ordering operators. These once meant "every component less (greater, ...) than", which is not a strict weak ordering: two different vectors can each fail to be less than the other, so std::set, std::map and std::sort built on them silently merge or misorder distinct vectors. Compare components explicitly, or use lessLX() for a lexicographic ordering. | |
| bool | operator< (const Vec3T< T > &u) const noexcept=delete |
| bool | operator> (const Vec3T< T > &u) const noexcept=delete |
| bool | operator<= (const Vec3T< T > &u) const noexcept=delete |
| bool | operator>= (const Vec3T< T > &u) const noexcept=delete |
Static Public Member Functions | |
| static constexpr Vec3T< T > | zeros () noexcept |
| Return a vector with x = y = z = 0. | |
| static constexpr Vec3T< T > | ones () noexcept |
| Return a vector with x = y = z = 1. | |
| static constexpr Vec3T< T > | unit (const size_t a_dir) noexcept |
| Return the unit basis vector for the given coordinate axis. | |
| static constexpr Vec3T< T > | min () noexcept |
| Return the most-negative representable vector. | |
| static constexpr Vec3T< T > | max () noexcept |
| Return the most-positive representable vector. | |
| static constexpr Vec3T< T > | infinity () noexcept |
| Return a vector with infinite components. | |
Protected Attributes | |
| Array< T, 3 > | m_X |
| Vector components. | |
Detailed Description
class EBGeometry::Vec3T< T >
Three-dimensional vector class with arithmetic operators.
The components are reached through operator[] (index 0, 1 or 2).
- Note
- Vec3T is the point and vector type used throughout EBGeometry. It is always 3D, i.e. independent of the application's spatial dimension.
- Template Parameters
-
T Floating-point precision (float or double).
Constructor & Destructor Documentation
◆ Vec3T() [1/3]
|
defaultnoexcept |
Default constructor. Leaves the components uninitialized.
Defaulted, so that Vec3T is trivially default constructible and can be the element type of a CUDA/HIP __shared__ array, which may not have an initializer. As with a plain T, Vec3T<T> v; leaves v uninitialized, while value initialization (Vec3T<T> v{};, Vec3T<T>()) zeroes it, as does zeros().
◆ Vec3T() [2/3]
|
constexprdefaultnoexcept |
Copy constructor.
- Parameters
-
[in] a_u Other vector
Sets *this = a_u
◆ Vec3T() [3/3]
|
constexprnoexcept |
Full constructor.
- Parameters
-
[in] a_x First vector component [in] a_y Second vector component [in] a_z Third vector component
Sets X[0] = a_x, X[1] = a_y and X[2] = a_z.
Member Function Documentation
◆ cross()
|
inlineconstexprnoexcept |
Vector cross product.
- Parameters
-
[in] u Other vector.
- Returns
- Cross product (*this) × u.
◆ dot()
|
inlineconstexprnoexcept |
Vector dot product.
- Parameters
-
[in] u Other vector.
- Returns
- Scalar dot product (*this) · u.
◆ infinity()
|
inlinestaticconstexprnoexcept |
Return a vector with infinite components.
- Returns
- Vector with each component equal to Math::Limits<T>::infinity().
◆ length()
|
inlinenoexcept |
Compute vector length.
Not constexpr, since std::sqrt is not.
- Returns
- Euclidean length: std::sqrt(X[0]*X[0] + X[1]*X[1] + X[2]*X[2]).
◆ length2()
|
inlineconstexprnoexcept |
Compute squared vector length.
- Returns
- Squared Euclidean length: X[0]*X[0] + X[1]*X[1] + X[2]*X[2].
◆ lessLX()
|
inlineconstexprnoexcept |
Lexicographic comparison (x first, then y, then z).
Returns true if this vector is lexicographically less than u, i.e. the first differing component of (*this) is less than the corresponding component of u.
- Parameters
-
[in] u Other vector.
- Returns
- True if (*this) is lexicographically less than u.
◆ max()
|
inlinestaticconstexprnoexcept |
Return the most-positive representable vector.
- Returns
- Vector with each component equal to Math::Limits<T>::max().
◆ maxDir()
|
inlinenoexcept |
Return the direction which has the largest component (can be absolute)
- Parameters
-
[in] a_doAbs If true, evaluate component magnitudes rather than values.
- Returns
- Direction with the biggest component
◆ min()
|
inlinestaticconstexprnoexcept |
Return the most-negative representable vector.
- Returns
- Vector with each component equal to -Math::Limits<T>::max().
◆ minDir()
|
inlinenoexcept |
Return the index of the smallest component (optionally by magnitude).
- Parameters
-
[in] a_doAbs If true, compare |X[i]| instead of X[i].
- Returns
- Index (0, 1, or 2) of the component with the smallest value (or magnitude).
◆ ones()
|
inlinestaticconstexprnoexcept |
Return a vector with x = y = z = 1.
- Returns
- Ones vector (1, 1, 1).
◆ operator!=()
|
inlineconstexprnoexcept |
Inequality comparison.
- Parameters
-
[in] u Other vector.
- Returns
- True if any component differs.
◆ operator*() [1/2]
|
inlineconstexprnoexcept |
Multiplication operator. Returns a vector with scalar multiplied components.
- Parameters
-
[in] s Scalar to multiply by
- Returns
- Returns a new vector with X[i] = this->X[i] * s
◆ operator*() [2/2]
|
inlineconstexprnoexcept |
Component-wise multiplication operator.
- Parameters
-
[in] s Scalar to multiply by
- Returns
- Returns a new vector with X[i] = this->X[i] * s[i] for each component.
◆ operator*=()
|
inlineconstexprnoexcept |
Vector multiplication operator.
- Parameters
-
[in] s Scalar to multiply by
- Returns
- (*this), with X[i] *= s for each component.
◆ operator+() [1/2]
|
inlineconstexprnoexcept |
Identity operator.
- Returns
- Copy of this vector (unary plus, component-wise identity).
◆ operator+() [2/2]
|
inlineconstexprnoexcept |
Addition operator.
- Parameters
-
[in] u Other vector.
- Returns
- New vector with X[i] = this->X[i] + u[i] for each component.
◆ operator+=()
|
inlineconstexprnoexcept |
Vector addition operator.
- Parameters
-
[in] u Vector to add
- Returns
- (*this), with X[i] += u[i] for each component.
◆ operator-() [1/2]
|
inlineconstexprnoexcept |
Negation operator.
- Returns
- New vector with each component negated.
◆ operator-() [2/2]
|
inlineconstexprnoexcept |
Subtraction operator. Returns a new vector with subtracted components.
- Returns
- New vector with X[i] = this->X[i] - u[i] for each component.
- Parameters
-
[in] u Other vector
◆ operator-=()
|
inlineconstexprnoexcept |
Vector subtraction operator.
- Parameters
-
[in] u Vector to subtract
- Returns
- (*this), with X[i] -= u[i] for each component.
◆ operator/() [1/2]
|
inlineconstexprnoexcept |
Division operator. Returns a vector with scalar divided components.
- Parameters
-
[in] s Scalar to divide by
- Returns
- Returns a new vector with X[i] = this->X[i] / s
◆ operator/() [2/2]
|
inlineconstexprnoexcept |
Component-wise division operator.
- Parameters
-
[in] v Other vector
- Returns
- Returns a new vector with X[i] = this->X[i]/v[i] for each component.
◆ operator/=()
|
inlineconstexprnoexcept |
In-place scalar division operator.
- Parameters
-
[in] s Scalar to divide by
- Returns
- (*this), with X[i] /= s for each component.
◆ operator=()
|
constexprdefaultnoexcept |
Assignment operator.
- Parameters
-
[in] u Other vector.
- Returns
- Reference to *this after assignment.
◆ operator==()
|
inlineconstexprnoexcept |
Equality comparison.
- Parameters
-
[in] u Other vector.
- Returns
- True if all three components are equal.
◆ operator[]() [1/2]
|
inlineconstexprnoexcept |
Const element access.
- Parameters
-
[in] i Component index (0 = x, 1 = y, 2 = z). Must be < 3.
- Returns
- Const reference to the i-th component.
◆ operator[]() [2/2]
|
inlineconstexprnoexcept |
Mutable element access.
- Parameters
-
[in] i Component index (0 = x, 1 = y, 2 = z). Must be < 3.
- Returns
- Reference to the i-th component.
◆ unit()
|
inlinestaticconstexprnoexcept |
Return the unit basis vector for the given coordinate axis.
- Parameters
-
[in] a_dir Axis index (0 = x, 1 = y, 2 = z).
- Returns
- Basis vector e_{a_dir} with a 1 in position a_dir and 0 elsewhere.
◆ zeros()
|
inlinestaticconstexprnoexcept |
Return a vector with x = y = z = 0.
- Returns
- Zero vector (0, 0, 0).
The documentation for this class was generated from the following file:
- Source/EBGeometry_Vec.hpp
