EBGeometry
Compact, header-only C++ library for fast evaluation of signed distance functions
Loading...
Searching...
No Matches
Public Types | Public Member Functions | Static Public Member Functions | List of all members
EBGeometry::SphereCloudBVH< T, K, W > Class Template Reference

A BVH over spheres of differing radii (polydisperse particles), with the signed distance to their union and the closest sphere. More...

#include <EBGeometry_SphereCloudBVH.hpp>

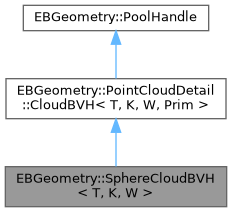
Inheritance diagram for EBGeometry::SphereCloudBVH< T, K, W >:
Inheritance graph
[legend]
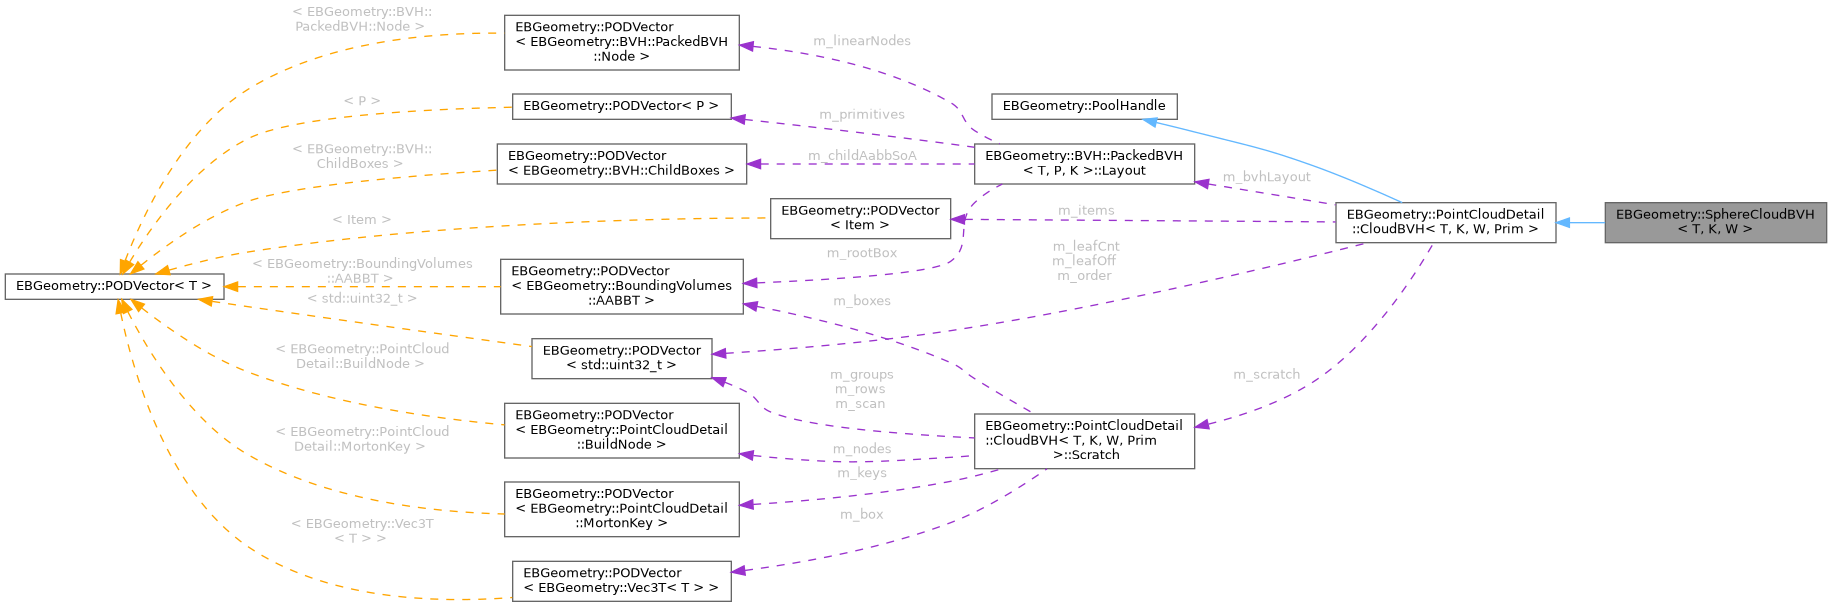
Collaboration diagram for EBGeometry::SphereCloudBVH< T, K, W >:
Collaboration graph
[legend]

Public Types

using Sphere = SphereCloud::Sphere< T >
 A sphere: a center and a radius.
 
using Hit = SphereCloud::Hit< T >
 One query result: the cloud index of a sphere and the signed distance to its surface.
 
using SphereGroup = SphereAoSoA< T, W >
 The SoA leaf primitive: a group of up to W spheres carrying their cloud indices.
 
using Packed = BVH::PackedBVH< T, SphereGroup, K >
 The packed BVH this class holds over its sphere groups.
 
using AABB = BoundingVolumes::AABBT< T >
 Axis-aligned bounding box type.
 
- Public Types inherited from EBGeometry::PointCloudDetail::CloudBVH< T, K, W, Prim >
using Item = typename Prim::Item
 What a source of the primitives returns.
 
using Group = typename Prim::Group
 The SoA leaf primitive: a group of up to W primitives carrying their cloud indices.
 
using Packed = BVH::PackedBVH< T, Group, K >
 The packed BVH over the groups.
 
using Node = typename Packed::Node
 Flat node type of the held BVH.
 
using AABB = BoundingVolumes::AABBT< T >
 Axis-aligned bounding box type.
 

Public Member Functions

 SphereCloudBVH (Pool &a_pool, const std::vector< Sphere > &a_spheres, std::size_t a_targetLeafSize=16 *W)
 Build a BVH over spheres on the host: shorthand for build(a_pool, a_spheres, a_targetLeafSize).
 
 SphereCloudBVH (Pool &a_pool, const std::vector< Vec3T< T > > &a_centers, const std::vector< T > &a_radii, std::size_t a_targetLeafSize=16 *W)
 Build a BVH over spheres given as centers and radii, on the host: shorthand for build(a_pool, a_centers, a_radii, a_targetLeafSize).
 
template<class Source >
void rebuild (const Source &a_source, uint32_t a_numSpheres)
 Build the BVH again, in the arrays build() reserved, from new spheres.
 
uint32_t maxSpheres () const noexcept
 The most spheres rebuild() can take.
 
T signedDistance (const Vec3T< T > &a_point) const noexcept
 Signed distance to the union of the spheres: min_i(|p - c_i| - r_i); see the class.
 
Hit closestSphere (const Vec3T< T > &a_point) const noexcept
 The sphere whose surface is nearest to a point, in the signed sense of signedDistance().
 
AABB computeBoundingVolume () const noexcept
 The box of all the spheres.
 
uint32_t numSpheres () const noexcept
 Number of spheres in the cloud.
 
Sphere sphere (uint32_t a_index) const noexcept
 The sphere with a cloud index.
 
Packed getBVH () const noexcept
 The held packed BVH over the sphere groups.
 
SphereCloudBVH rebasedView (const Pool &a_pool) const noexcept
 Produce a copy of this object that resolves against a_pool.
 
SphereCloudBVH deepCopy (Pool &a_dstPool) const
 Duplicate this object's storage into a_dstPool.
 
void * base () noexcept
 The base address this object's arrays are offsets from; see PoolHandle::base().
 
const void * base () const noexcept
 The base address this object's arrays are offsets from; see PoolHandle::base().
 
- Public Member Functions inherited from EBGeometry::PoolHandle
PoolLocation location () const noexcept
 Where this handle's arrays live.
 
bool isAttachedTo (const Pool &a_pool) const noexcept
 Check whether this handle's arrays were reserved from a_pool.
 

Static Public Member Functions

template<class Source >
static SphereCloudBVH build (Pool &a_pool, const Source &a_source, uint32_t a_numSpheres, std::size_t a_targetLeafSize=16 *W, uint32_t a_maxSpheres=0)
 Build a BVH over spheres, where the pool's memory is.
 
static SphereCloudBVH build (Pool &a_pool, const std::vector< Sphere > &a_spheres, std::size_t a_targetLeafSize=16 *W, uint32_t a_maxSpheres=0)
 Build a BVH over spheres on the host, where the pool's memory is; see the build() above.
 
static SphereCloudBVH build (Pool &a_pool, const std::vector< Vec3T< T > > &a_centers, const std::vector< T > &a_radii, std::size_t a_targetLeafSize=16 *W, uint32_t a_maxSpheres=0)
 Build a BVH over spheres given as centers and radii, on the host, where the pool's memory is; see the build() above.
 

Additional Inherited Members

- Protected Member Functions inherited from EBGeometry::PointCloudDetail::CloudBVH< T, K, W, Prim >
 CloudBVH () noexcept=default
 An empty BVH, to be reserved and filled.
 
template<class Source >
void initialize (Pool &a_pool, const Source &a_source, uint32_t a_numItems, std::size_t a_targetLeafSize, uint32_t a_maxItems, const char *a_who)
 Build over the primitives of a source, where the pool's memory is: the body of PointCloudBVH::build().
 
void initialize (Pool &a_pool, const std::vector< Item > &a_items, std::size_t a_targetLeafSize, uint32_t a_maxItems, const char *a_who)
 Build over the primitives of a host array, where the pool's memory is: for a pool in device memory, the primitives are checked on the host and copied to scratch there first.
 
template<class Source >
void reinitialize (const Source &a_source, uint32_t a_numItems, const char *a_who)
 Build again in the arrays initialize() reserved: the body of PointCloudBVH::rebuild().
 
void rebase (const Pool &a_pool) noexcept
 Resolve this object against a_pool: the body of PointCloudBVH::rebasedView(), on a copy.
 
void copyInto (CloudBVH &a_copy, Pool &a_dstPool) const
 Duplicate this object's storage into a_dstPool, for a_copy, a copy of this object: the body of PointCloudBVH::deepCopy().
 
void reserveArrays (Pool &a_pool, const Sizes &a_sizes, uint32_t a_numItems)
 Reserve the BVH's and the cloud's arrays from a_pool.
 
template<class Source >
Sizes shape (const Scratch &a_scratch, void *a_base, const Source &a_source, uint32_t a_numItems, const char *a_who)
 Build steps 1 to 5 (see PointCloudBVH): the box, the sorted keys, the tree's levels, the subtree sizes, boxes and depth-first indices, and the scans that place the rows and the groups.
 
template<class Source >
void write (const Scratch &a_scratch, void *a_base, const Sizes &a_sizes, const Source &a_source, uint32_t a_numItems)
 Build step 6 (see PointCloudBVH): write the arrays reserved for the tree shape() gave.
 
template<class F >
void run (std::size_t a_count, const F &a_f) const
 Run a build step: through GPU::parallelFor() for a build there, and in a host loop otherwise.
 
std::uint32_t scan (std::uint32_t *a_values, std::uint32_t a_count, std::uint32_t *a_scratch) const
 An exclusive scan, where the build runs; see GPU::exclusiveScan().
 
- Protected Member Functions inherited from EBGeometry::PoolHandle
 PoolHandle () noexcept=default
 An unset location; the first reservation attaches it.
 
 PoolHandle (const PoolLocation &a_location) noexcept
 Adopt a location, as a handle rebuilt from a stored layout does.
 
 PoolHandle (const PoolHandle &) noexcept=default
 Copy a handle, as a derived handle's copy does.
 
 PoolHandle (PoolHandle &&) noexcept=default
 Move a handle; the same as a copy.
 
PoolHandle & operator= (const PoolHandle &) noexcept=default
 Copy-assign a handle, as a derived handle's assignment does.
 
PoolHandle & operator= (PoolHandle &&) noexcept=default
 Move-assign a handle; the same as a copy.
 
 ~PoolHandle () noexcept=default
 Destructor; protected, since a PoolHandle exists only as the base of a handle.
 
void * base () noexcept
 The base address this handle's offsets resolve against; see PoolLocation::base().
 
const void * base () const noexcept
 The base address this handle's offsets resolve against, for read-only access.
 
void attach (const Pool &a_pool, const char *a_who, const bool a_deviceWritten=false) noexcept
 Follow a_pool, as the first reservation does; see PoolLocation::attach().
 
PoolLocation rebasedLocation (const Pool &a_pool, uint64_t a_endByte, const char *a_who) const noexcept
 The location of this handle's arrays in another pool of its mirror chain; see PoolLocation::rebasedOnto().
 
void setLocation (const PoolLocation &a_location) noexcept
 Replace the location, for a view or a copy made by a derived handle.
 
- Static Protected Member Functions inherited from EBGeometry::PointCloudDetail::CloudBVH< T, K, W, Prim >
static Sizes sizesFor (uint32_t a_numItems, uint32_t a_leafSize, const char *a_who) noexcept
 Bounds on the array sizes of a build over a_numItems primitives.
 
static Scratch reserveScratch (Pool &a_pool, uint32_t a_numItems, uint32_t a_leafSize, const char *a_who)
 Reserve a build's scratch from a_pool, for up to a_numItems primitives.
 
template<class U >
static std::vector< U > toHost (const PODVector< U > &a_array, const void *a_base)
 Copy one pool-resident array back into a host std::vector.
 
- Protected Attributes inherited from EBGeometry::PointCloudDetail::CloudBVH< T, K, W, Prim >
Packed::Layout m_bvhLayout
 The packed BVH over the groups, as a layout: it shares this object's location.
 
PODVector< Item > m_items
 The primitives, indexed by cloud index.
 
PODVector< std::uint32_t > m_leafOff
 Per-primitive own-leaf group offset (for seeding).
 
PODVector< std::uint32_t > m_leafCnt
 Per-primitive own-leaf group count (for seeding).
 
PODVector< std::uint32_t > m_order
 Cloud indices in leaf (build) order; the spatially coherent batch-query order.
 
Scratch m_scratch
 The scratch arrays a rebuild uses; empty for a BVH without room for one.
 
std::uint32_t m_maxItems = 0
 The most primitives a rebuild can take, 0 for none.
 
std::uint32_t m_leafSize = 0
 The largest leaf, max(a_targetLeafSize, K): a node of more primitives is cut.
 
std::uint32_t m_depth = 0
 The tree's depth in node levels (the root is level 1), 0 for an empty cloud.
 
bool m_parallel = false
 Whether the build runs through GPU::parallelFor() (the pool's memory is device-accessible).
 

Detailed Description

template<class T, size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
class EBGeometry::SphereCloudBVH< T, K, W >

A BVH over spheres of differing radii (polydisperse particles), with the signed distance to their union and the closest sphere.

A shape: signedDistance() and computeBoundingVolume(), negative inside a sphere. The distance is min_i(|p - c_i| - r_i) over the spheres: exact outside their union, and inside it a bound in magnitude (where spheres overlap, the union's surface can be farther than every sphere's own), as for a Union of the spheres. Spheres of one radius need no SphereCloudBVH: the distance from a PointCloudBVH of the centers, less the radius, is the same.

The build is PointCloudBVH's linear build (see there), over the centers: the Morton keys and cuts come from the centers, and every box is grown by its spheres' radii. It runs where the pool's memory is, on a device included, and every side gives the same tree. The leaves are SphereAoSoA groups carrying each sphere's cloud index, which closestSphere() reports.

Note
Device portability, as for PointCloudBVH: the packed BVH and the cloud's arrays are reserved from one Pool and the class stores only offsets into it, so it is trivially copyable. Freeze and mirror the pool, call rebasedView(), and pass the value into a kernel; signedDistance(), closestSphere() and computeBoundingVolume() are device-callable. The pool must outlive the BVH and every copy of it.
Template Parameters
TFloating-point precision.
KBVH branching factor. Defaults to BVH::DefaultBranchingRatio<T>().
WSpheres per SoA leaf group. Defaults to PointSoA::DefaultWidth<T>().

Constructor & Destructor Documentation

◆ SphereCloudBVH() [1/2]

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
EBGeometry::SphereCloudBVH< T, K, W >::SphereCloudBVH ( Pool &  a_pool,
const std::vector< Sphere > &  a_spheres,
std::size_t  a_targetLeafSize = 16 *W 
)
inline

Build a BVH over spheres on the host: shorthand for build(a_pool, a_spheres, a_targetLeafSize).

A sphere's cloud index, which the queries report, is its position in a_spheres.

Parameters
[in,out]a_poolPool the BVH's arrays are reserved from; must outlive this object.
[in]a_spheresThe spheres. At most 2^31; centers and radii finite, radii at least 0.
[in]a_targetLeafSizeTarget spheres per leaf. Must be at least 1.

◆ SphereCloudBVH() [2/2]

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
EBGeometry::SphereCloudBVH< T, K, W >::SphereCloudBVH ( Pool &  a_pool,
const std::vector< Vec3T< T > > &  a_centers,
const std::vector< T > &  a_radii,
std::size_t  a_targetLeafSize = 16 *W 
)
inline

Build a BVH over spheres given as centers and radii, on the host: shorthand for build(a_pool, a_centers, a_radii, a_targetLeafSize).

A sphere's cloud index is its position in a_centers and a_radii.

Parameters
[in,out]a_poolPool the BVH's arrays are reserved from; must outlive this object.
[in]a_centersThe centers. At most 2^31, all finite.
[in]a_radiiThe radii, as many as the centers. All finite and at least 0.
[in]a_targetLeafSizeTarget spheres per leaf. Must be at least 1.

Member Function Documentation

◆ base() [1/2]

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
const void * EBGeometry::PoolHandle::base ( ) const
inlinenoexcept

The base address this object's arrays are offsets from; see PoolHandle::base().

Returns
The base address: const void* for a const object, void* otherwise.

◆ base() [2/2]

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
void * EBGeometry::PoolHandle::base ( )
inlinenoexcept

The base address this object's arrays are offsets from; see PoolHandle::base().

Returns
The base address: const void* for a const object, void* otherwise.

◆ build() [1/3]

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
template<class Source >
static SphereCloudBVH EBGeometry::SphereCloudBVH< T, K, W >::build ( Pool &  a_pool,
const Source &  a_source,
uint32_t  a_numSpheres,
std::size_t  a_targetLeafSize = 16 *W,
uint32_t  a_maxSpheres = 0 
)
inlinestatic

Build a BVH over spheres, where the pool's memory is.

As PointCloudBVH::build(), over the centers, with every box grown by the radii: it runs through GPU::parallelFor() for a pool in device-accessible memory (reading a_source on the device in a CUDA or HIP translation unit), and on the host otherwise, and both give the same tree. A sphere with a non-finite center or radius, or a negative radius, is rejected (on the host by its index). With a_maxSpheres, the arrays are reserved for any cloud of that many spheres, so that rebuild() reserves nothing and works on a frozen pool.

Template Parameters
SourceA source of spheres: a trivially copyable type whose const call operator takes a cloud index (uint32_t) and returns that sphere; SphereCloud::FromArray, or SphereCloud::FromCentersAndRadii for centers and radii kept apart.
Parameters
[in,out]a_poolPool the BVH's arrays are reserved from; must outlive the BVH.
[in]a_sourceThe spheres.
[in]a_numSpheresNumber of spheres. At most 2^31.
[in]a_targetLeafSizeTarget spheres per leaf (a node of at most max(a_targetLeafSize, K) spheres is a leaf). Must be at least 1.
[in]a_maxSpheresMost spheres a rebuild() may have; 0 for no rebuild(), and the arrays this cloud needs only. At least a_numSpheres otherwise.
Returns
The BVH.

◆ build() [2/3]

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
static SphereCloudBVH EBGeometry::SphereCloudBVH< T, K, W >::build ( Pool &  a_pool,
const std::vector< Sphere > &  a_spheres,
std::size_t  a_targetLeafSize = 16 *W,
uint32_t  a_maxSpheres = 0 
)
inlinestatic

Build a BVH over spheres on the host, where the pool's memory is; see the build() above.

For a pool in device memory, the spheres are first copied to scratch there.

Parameters
[in,out]a_poolPool the BVH's arrays are reserved from; must outlive the BVH.
[in]a_spheresThe spheres. At most 2^31; centers and radii finite, radii at least 0.
[in]a_targetLeafSizeTarget spheres per leaf. Must be at least 1.
[in]a_maxSpheresMost spheres a rebuild() may have (see the build() above).
Returns
The BVH.

◆ build() [3/3]

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
static SphereCloudBVH EBGeometry::SphereCloudBVH< T, K, W >::build ( Pool &  a_pool,
const std::vector< Vec3T< T > > &  a_centers,
const std::vector< T > &  a_radii,
std::size_t  a_targetLeafSize = 16 *W,
uint32_t  a_maxSpheres = 0 
)
inlinestatic

Build a BVH over spheres given as centers and radii, on the host, where the pool's memory is; see the build() above.

For a pool in device memory, the centers and radii are first copied to scratch there.

Parameters
[in,out]a_poolPool the BVH's arrays are reserved from; must outlive the BVH.
[in]a_centersThe centers. At most 2^31, all finite.
[in]a_radiiThe radii, as many as the centers. All finite and at least 0.
[in]a_targetLeafSizeTarget spheres per leaf. Must be at least 1.
[in]a_maxSpheresMost spheres a rebuild() may have (see the build() above).
Returns
The BVH.

◆ closestSphere()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
Hit EBGeometry::SphereCloudBVH< T, K, W >::closestSphere ( const Vec3T< T > &  a_point) const
inlinenoexcept

The sphere whose surface is nearest to a point, in the signed sense of signedDistance().

Ties go to the lower cloud index.

Parameters
[in]a_pointQuery point. Must be finite (checked only with assertions on).
Returns
The sphere's cloud index and the signed distance to its surface; a miss for an empty cloud.

◆ computeBoundingVolume()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
AABB EBGeometry::SphereCloudBVH< T, K, W >::computeBoundingVolume ( ) const
inlinenoexcept

The box of all the spheres.

Returns
The root box: every sphere, grown by its radius. An empty box for an empty cloud.

◆ deepCopy()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
SphereCloudBVH EBGeometry::SphereCloudBVH< T, K, W >::deepCopy ( Pool &  a_dstPool) const
inline

Duplicate this object's storage into a_dstPool.

Parameters
[in,out]a_dstPoolPool the copy's arrays are reserved from; must outlive the copy.
Returns
An independent BVH over the same spheres. It has no room for a rebuild().

◆ getBVH()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
Packed EBGeometry::SphereCloudBVH< T, K, W >::getBVH ( ) const
inlinenoexcept

The held packed BVH over the sphere groups.

Returns
A PackedBVH that shares this object's location.

◆ maxSpheres()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
uint32_t EBGeometry::SphereCloudBVH< T, K, W >::maxSpheres ( ) const
inlinenoexcept

The most spheres rebuild() can take.

Returns
build()'s a_maxSpheres; 0 for a BVH built without room for a rebuild.

◆ numSpheres()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
uint32_t EBGeometry::SphereCloudBVH< T, K, W >::numSpheres ( ) const
inlinenoexcept

Number of spheres in the cloud.

Returns
The number of spheres.

◆ rebasedView()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
SphereCloudBVH EBGeometry::SphereCloudBVH< T, K, W >::rebasedView ( const Pool &  a_pool) const
inlinenoexcept

Produce a copy of this object that resolves against a_pool.

For a pool mirrored from this object's pool (Pool::mirror()): the returned value reads the mirror, on a device included. Copies nothing.

Parameters
[in]a_poolThe pool to resolve against: this object's pool, or a mirror of it.
Returns
The view.

◆ rebuild()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
template<class Source >
void EBGeometry::SphereCloudBVH< T, K, W >::rebuild ( const Source &  a_source,
uint32_t  a_numSpheres 
)
inline

Build the BVH again, in the arrays build() reserved, from new spheres.

As PointCloudBVH::rebuild(): the same tree as a new build() from these spheres, reserving nothing in the pool, so it works on a frozen pool. Needs room reserved by build()'s a_maxSpheres; more spheres than maxSpheres() is rejected. A view taken with rebasedView() before the rebuild still describes the old tree: take a new one. Call it on the BVH build() returned, not on a view or a deepCopy().

Template Parameters
SourceA source of spheres, as for build().
Parameters
[in]a_sourceThe spheres.
[in]a_numSpheresNumber of spheres, at most maxSpheres().

◆ signedDistance()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
T EBGeometry::SphereCloudBVH< T, K, W >::signedDistance ( const Vec3T< T > &  a_point) const
inlinenoexcept

Signed distance to the union of the spheres: min_i(|p - c_i| - r_i); see the class.

Parameters
[in]a_pointQuery point. Must be finite (checked only with assertions on).
Returns
The signed distance, negative inside a sphere; Math::Limits<T>::max() for an empty cloud.

◆ sphere()

template<class T , size_t K = BVH::DefaultBranchingRatio<T>(), size_t W = PointSoA::DefaultWidth<T>()>
Sphere EBGeometry::SphereCloudBVH< T, K, W >::sphere ( uint32_t  a_index) const
inlinenoexcept

The sphere with a cloud index.

Parameters
[in]a_indexCloud index, less than numSpheres().
Returns
The sphere.

The documentation for this class was generated from the following file: