The ray forms (see RayForm) of the mesh SDFs. TriMeshSDF: its BVH walked along the ray (PackedBVH::traverse() with BVH::RayQuery), and its triangles crossed exactly (TriangleRay::crossing()). MeshSDF: the same walk, its polygon faces crossed exactly (DCEL::FaceT::rayCrossing()). FlatMeshSDF: every face, without a BVH. With this header included, firstHit() and intersects() on a mesh SDF are exact instead of marched, and so are compositions of mesh SDFs (see EBGeometry_CSGRayForms.hpp), through spans(): the crossings along the ray, nearest first, paired into spans by the side of the face the ray crosses from. A closed mesh is needed for the spans to mean inside and outside. More...
#include <cstddef>#include <cstdint>#include "EBGeometry_MeshDistanceFunctions.hpp"#include "EBGeometry_Ray.hpp"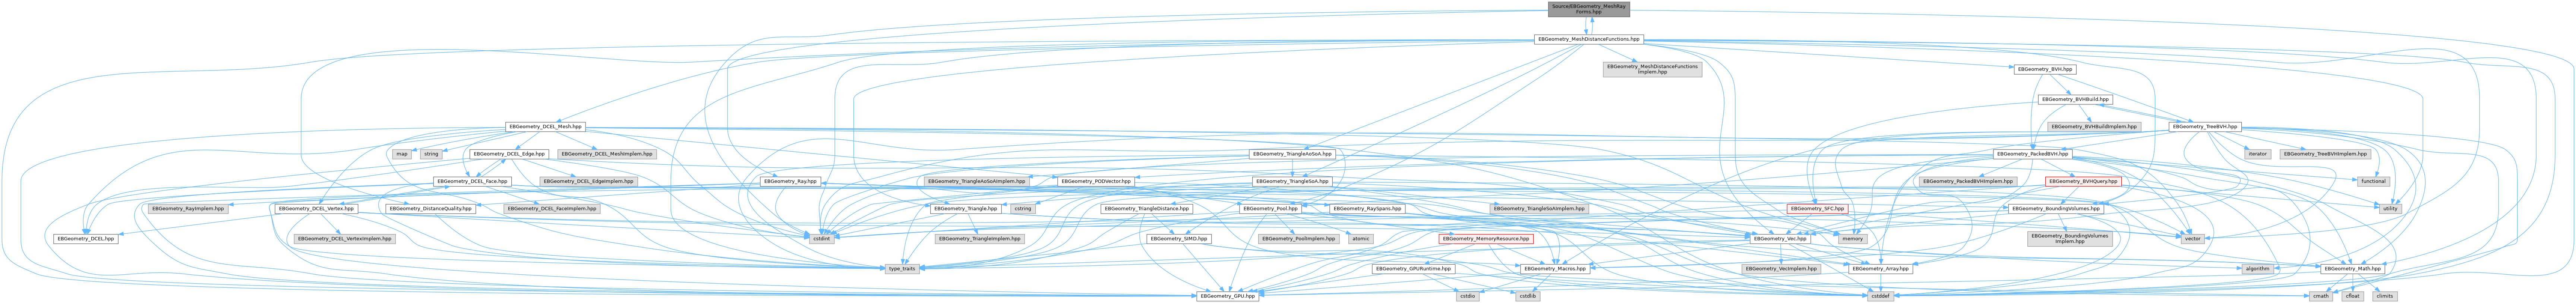
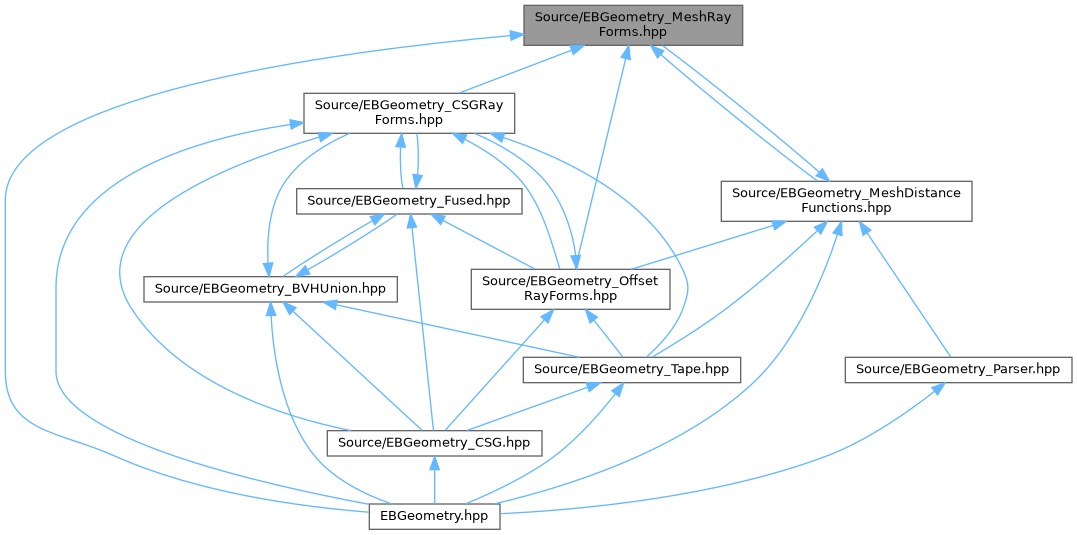
Go to the source code of this file.
Classes | |
| struct | EBGeometry::RayForm< TriMeshSDF< T, K, W > > |
| TriMeshSDF's ray form: the nearest triangle the ray crosses, found by walking the BVH nearest box first and stopping at boxes farther than the nearest crossing so far. Exact, and callable on a device. More... | |
| struct | EBGeometry::RayForm< MeshSDF< T, K > > |
| MeshSDF's ray form: the nearest polygon face the ray crosses, found by walking the BVH nearest box first and stopping at boxes farther than the nearest crossing so far. Exact, and callable on a device. More... | |
| struct | EBGeometry::RayForm< FlatMeshSDF< T > > |
| FlatMeshSDF's ray form: every face tested, as FlatMeshSDF's signed distance tests every face (no BVH). Exact, and callable on a device; as for MeshSDF otherwise. More... | |
| struct | EBGeometry::RayDetail::NearestCrossings< T > |
| The nearest crossings of a mesh along a ray, in order, as a BVH walk finds them: at most Capacity, enough for the spans a list holds and one more. More... | |
| struct | EBGeometry::RayDetail::NearestCrossings< T >::Crossing |
| A crossing. More... | |
Namespaces | |
| namespace | EBGeometry |
| Namespace containing all of EBGeometry's functionality. | |
Functions | |
| template<class T > | |
| HitT< T > | EBGeometry::RayDetail::faceHit (const RayT< T > &a_ray, const T a_t, const uint32_t a_face, const Vec3T< T > &a_normal) noexcept |
| A crossing of a mesh face as a HitT. | |
Detailed Description
The ray forms (see RayForm) of the mesh SDFs. TriMeshSDF: its BVH walked along the ray (PackedBVH::traverse() with BVH::RayQuery), and its triangles crossed exactly (TriangleRay::crossing()). MeshSDF: the same walk, its polygon faces crossed exactly (DCEL::FaceT::rayCrossing()). FlatMeshSDF: every face, without a BVH. With this header included, firstHit() and intersects() on a mesh SDF are exact instead of marched, and so are compositions of mesh SDFs (see EBGeometry_CSGRayForms.hpp), through spans(): the crossings along the ray, nearest first, paired into spans by the side of the face the ray crosses from. A closed mesh is needed for the spans to mean inside and outside.
Function Documentation
◆ faceHit()
|
inlinenoexcept |
A crossing of a mesh face as a HitT.
Internal helper; not part of the public API.
- Template Parameters
-
T Floating-point precision.
- Parameters
-
[in] a_ray Ray. [in] a_t Distance along the ray, or +infinity for none. [in] a_face The face's id. [in] a_normal The face's outward unit normal.
- Returns
- The hit, or a miss.
