NestedBVH
Places one surface mesh many times, in the two ways EBGeometry offers: shared between translated
placements in a Tape alongside analytic shapes, and as separate copies under a BVHUnion,
which nests one BVH (over the placements) above another (over each mesh’s triangles). Both are
evaluated on the host and, through the same query, on a GPU.
The source is at Examples/NestedBVH/main.cpp. See Building for how to compile
it with CMake, GNU Make, or a direct compiler invocation.
cd Examples/NestedBVH
./NestedBVH.ex                       # defaults to ../data/dodecahedron.stl
./NestedBVH.ex path/to/mesh.stl      # place your own mesh
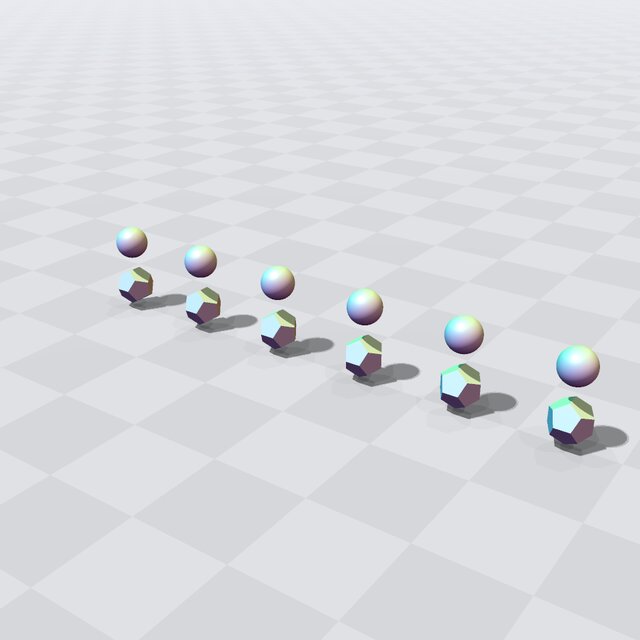
Fig. 28 The tape that places the mesh among the spheres.
Reading the mesh
The mesh is read into a
TriMeshSDF with
Parser::readIntoTriMeshSDF, using the default
BVH branching factor and triangle-group width. A TriMeshSDF with those defaults is a built-in
primitive of Tape<T>; one with any other must be listed as a user type. Everything the program
builds (meshes, BVHs, the tape, the union) is reserved from one
Pool, which must outlive all of it.
Many copies: a nested BVH
The mesh’s triangles are read once with Parser::readIntoTriangles, and each of 16 placements on
a 4 x 4 grid gets its own translated copy, built into its own TriMeshSDF with its own inner BVH.
A BVHUnion holds primitives of one type by value
and builds an outer BVH over their bounding boxes (see BVH-accelerated unions):
const EBGeometry::BVHUnion<T, Mesh, K> nested(pool, copies, boxes);
One query therefore descends two levels: the outer BVH finds the placements near the point, and each of those meshes’ own BVH finds the nearest triangle (see Bounding volume hierarchies). Since each placement is a separate mesh, genuinely different meshes of the same type can be placed the same way. Sharing one mesh between placements is what the tape is for.
Using them on the host
Both scenes are shapes: signedDistance(point) is negative inside any placement and positive
outside all of them. The program prints both at points along the first row of placements, which the
two scenes share: through the center of a placement, then halfway to the next one, and so on.
The same query on a GPU
The query is a trivially copyable functor holding the tape and the nested union by value. Both are
descriptors of what they built in the pool, so the last section freezes the pool, mirrors it in one
piece into GPU::memoryResource(), and rebases both onto the copy, every mesh with them.
GPU::transform then runs the query once per
point, both levels of BVH traversal included: in a kernel in a CUDA or HIP build, and in a host loop
otherwise. See Running on a GPU.
Looking at it
The example ends with Render::view(composed, pool, argc, argv), a window on the tape that places the mesh
among the spheres.
The window needs SDL2 and is built with make VIEWER=SDL2 or cmake -DEBGEOMETRY_VIEWER=SDL2 (see
The viewer window (EBGEOMETRY_VIEWER)); otherwise, and with --no-view or without a display, view() prints why
and returns. Drag to orbit and scroll to zoom; the window lists its other keys (see
The viewer’s keys).