The pointer-based, host-only BVH used for building: TreeBVH, the partitioners and the leaf predicate, and pack()/packWith() into a PackedBVH. More...
#include <algorithm>#include <cmath>#include <cstddef>#include <cstdint>#include <functional>#include <iterator>#include <memory>#include <type_traits>#include <utility>#include <vector>#include "EBGeometry_Array.hpp"#include "EBGeometry_BoundingVolumes.hpp"#include "EBGeometry_Macros.hpp"#include "EBGeometry_Math.hpp"#include "EBGeometry_PackedBVH.hpp"#include "EBGeometry_SFC.hpp"#include "EBGeometry_Vec.hpp"#include "EBGeometry_TreeBVHImplem.hpp"#include "EBGeometry_BVHBuild.hpp"
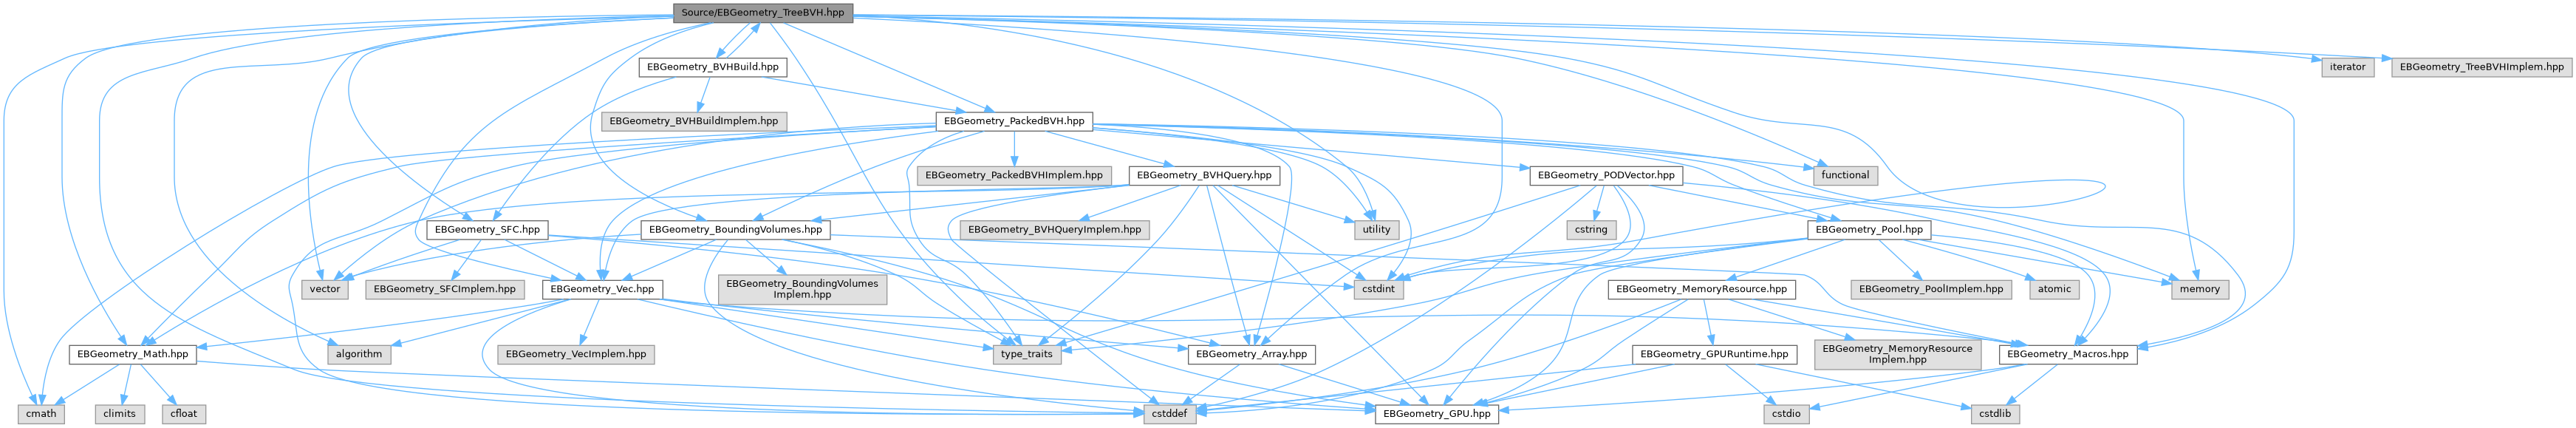
Include dependency graph for EBGeometry_TreeBVH.hpp:
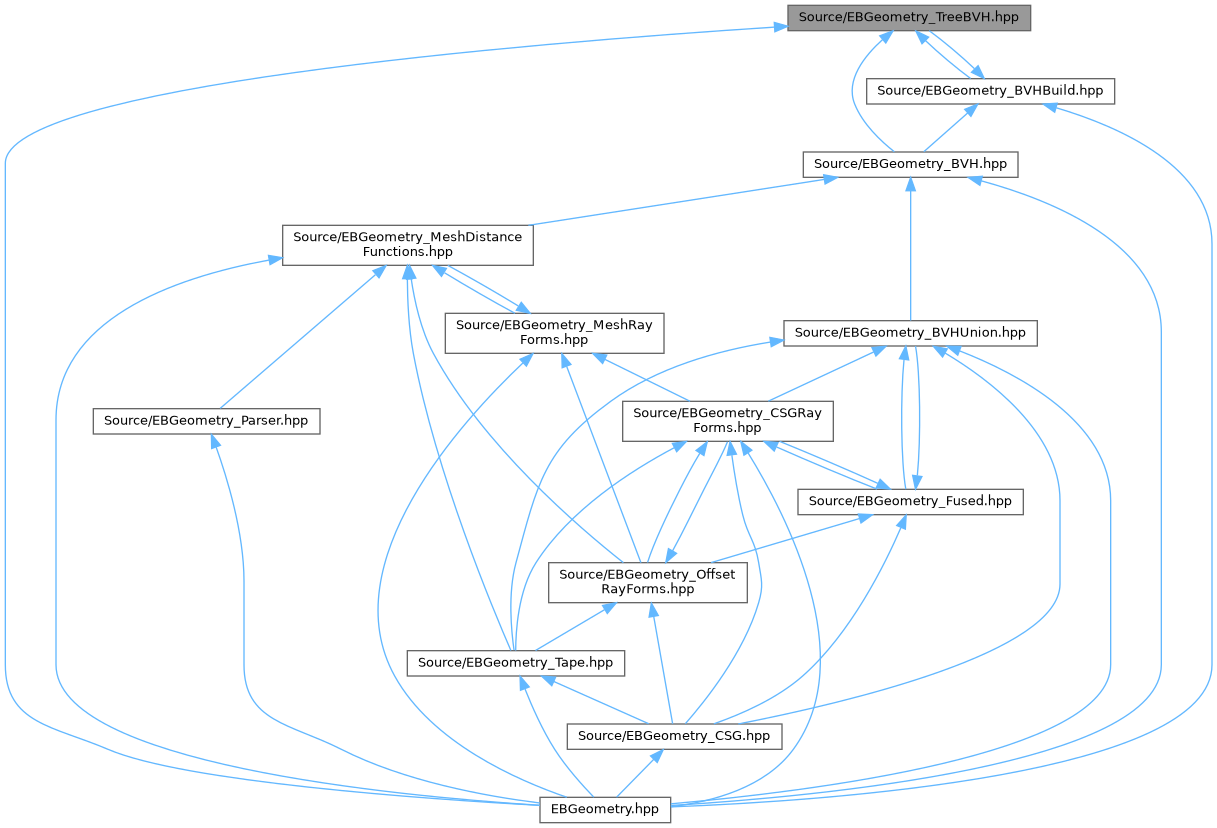
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | EBGeometry::BVH::TreeBVH< T, P, BV, K > |
| Forward declaration of the tree-structured BVH, defined in EBGeometry_TreeBVH.hpp. Needed by LeafPredicate and by PackedBVH's constructor from a TreeBVH. More... | |
Namespaces | |
| namespace | EBGeometry |
| Namespace containing all of EBGeometry's functionality. | |
| namespace | EBGeometry::BVH |
| Namespace for various bounding volume hierarchy (BVH) functionalities. | |
| namespace | EBGeometry::BVH::detail |
| Build-phase helpers shared by PackedBVH's constructors and static builds. Not part of the public API. | |
Functions | |
| template<class P > | |
| void | EBGeometry::BVH::detail::appendTreeLeaf (std::vector< P > &a_dst, const PrimitiveList< P > &a_leafPrims) |
| Append one TreeBVH leaf's primitives to a flat primitive array under construction. | |
| template<class List , size_t K> | |
| void | EBGeometry::BVH::detail::requireNonEmptyPartitions (const Array< List, K > &a_partitions, const size_t a_numInput, const char *a_who) |
| Abort unless every partition a partitioner returned holds at least one primitive. | |
| template<class P > | |
| void | EBGeometry::BVH::detail::appendAliased (std::vector< P > &a_dst, const std::shared_ptr< std::vector< P > > &a_block) |
| Materialise a single contiguous buffer into a flat primitive array under construction. | |
| void | EBGeometry::BVH::detail::requireLeafSetting (const char *a_who, const Construction a_construction, const ConstructionOptions &a_options) noexcept |
Abort unless the leaf-size setting that a_construction reads is positive. | |
| template<class T , class P , class BV > | |
| size_t | EBGeometry::BVH::SAH2WaySplit (PrimAndBVList< P, BV > &a_list, const size_t a_begin, const size_t a_end, const bool a_longestAxisOnly=false) noexcept |
| Internal helper: 2-way binned SAH split on the sub-range [a_begin, a_end). | |
| template<class T , class P , class BV > | |
| void | EBGeometry::BVH::SAHKWaySplit (PrimAndBVList< P, BV > &a_list, const size_t a_begin, const size_t a_end, const size_t a_K, std::vector< std::pair< size_t, size_t > > &a_groups, const bool a_longestAxisOnly=false) |
| Internal helper: recursively split [a_begin, a_end) into a_K groups via 2-way SAH. | |
| template<class T , class P , class BV > | |
| size_t | EBGeometry::BVH::Midpoint2WaySplit (PrimAndBVList< P, BV > &a_list, const size_t a_begin, const size_t a_end) noexcept |
| Internal helper: 2-way spatial-midpoint split on the sub-range [a_begin, a_end). | |
| template<class T , class P , class BV > | |
| void | EBGeometry::BVH::MidpointKWaySplit (PrimAndBVList< P, BV > &a_list, const size_t a_begin, const size_t a_end, const size_t a_K, std::vector< std::pair< size_t, size_t > > &a_groups) |
| Internal helper: recursively split [a_begin, a_end) into a_K groups via 2-way midpoint splits. | |
Variables | |
| template<class X , size_t K> | |
| auto | EBGeometry::BVH::EqualCounts |
| Utility: split a vector into K almost-equal contiguous chunks. | |
| template<class T , class P , class BV , size_t K> | |
| auto | EBGeometry::BVH::PrimitiveCentroidPartitioner |
| Partitioner that sorts primitives by centroid along the longest axis and splits into K pieces. | |
| template<class T , class P , class BV , size_t K> | |
| auto | EBGeometry::BVH::BVCentroidPartitioner |
| Partitioner that sorts primitives by bounding-volume centroid along the longest axis and splits into K pieces. | |
| template<class T , class P , class BV , size_t K, bool LongestAxisOnly = false> | |
| auto | EBGeometry::BVH::BinnedSAHPartitioner |
| Partitioner using binned SAH with recursive 2-way subdivision into K groups. | |
| template<class T , class P , class BV , size_t K> | |
| auto | EBGeometry::BVH::MidpointPartitioner |
| Partitioner that recursively bisects primitives by spatial midpoint (no sorting). | |
| template<class T , class P , class BV , size_t K> | |
| auto | EBGeometry::BVH::DefaultLeafPredicate |
| Default stop function: stop partitioning when the node holds fewer than K primitives. | |
Detailed Description
The pointer-based, host-only BVH used for building: TreeBVH, the partitioners and the leaf predicate, and pack()/packWith() into a PackedBVH.
The flexible host builder: TreeBVH partitions a list of (primitive, bounding volume) pairs with any partitioner and leaf predicate, then packs into the device-callable PackedBVH (EBGeometry_PackedBVH.hpp). PackedBVH's static builds that partition a primitive list directly, and the constructors pack() calls, are in EBGeometry_BVHBuild.hpp, which this header includes so that pack() works.
