The flattened, device-callable bounding volume hierarchy: PackedBVH, its node layout, traversals and the types shared with the builders. More...
#include <cmath>#include <cstddef>#include <cstdint>#include <functional>#include <memory>#include <type_traits>#include <utility>#include <vector>#include "EBGeometry_Array.hpp"#include "EBGeometry_BVHQuery.hpp"#include "EBGeometry_BoundingVolumes.hpp"#include "EBGeometry_Macros.hpp"#include "EBGeometry_Math.hpp"#include "EBGeometry_PODVector.hpp"#include "EBGeometry_Pool.hpp"#include "EBGeometry_Vec.hpp"#include "EBGeometry_PackedBVHImplem.hpp"
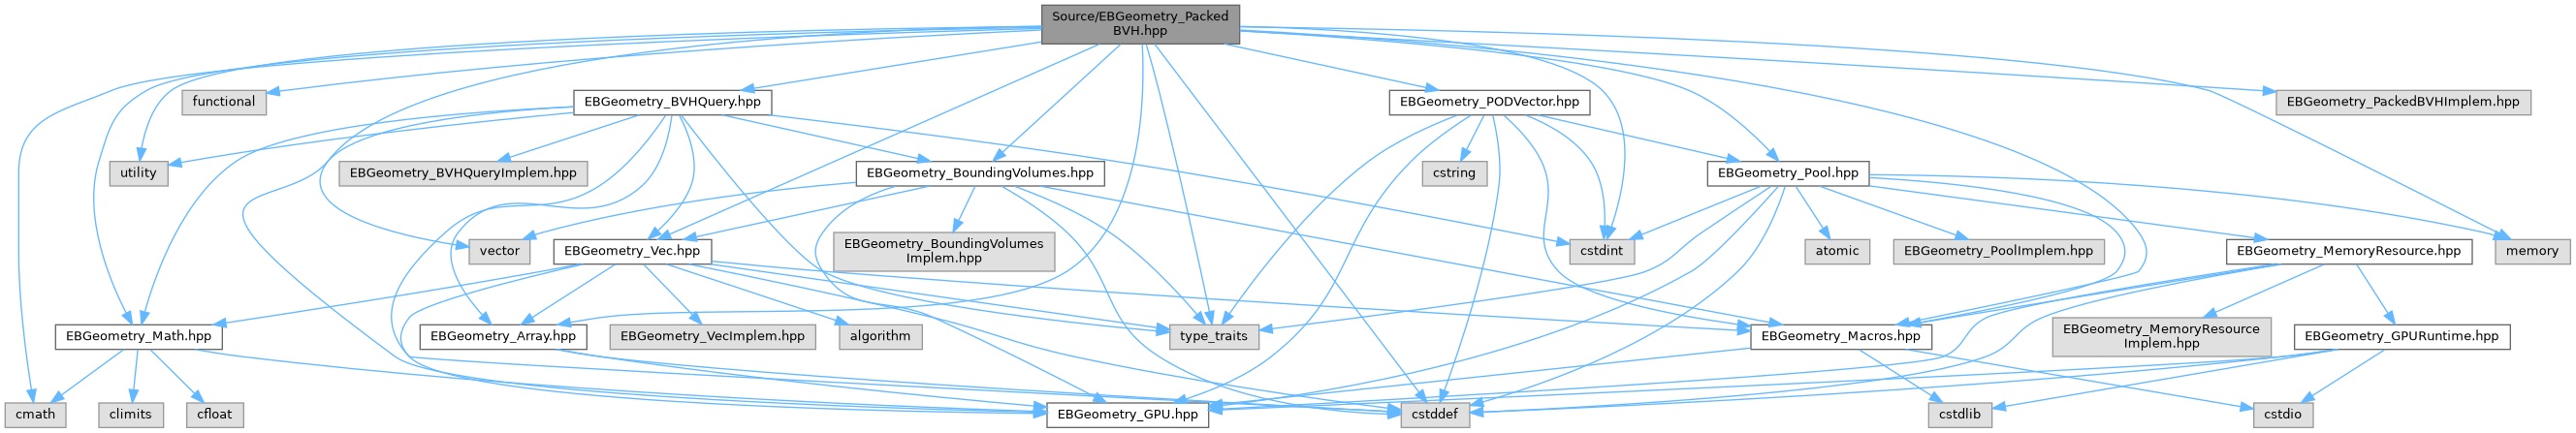
Include dependency graph for EBGeometry_PackedBVH.hpp:
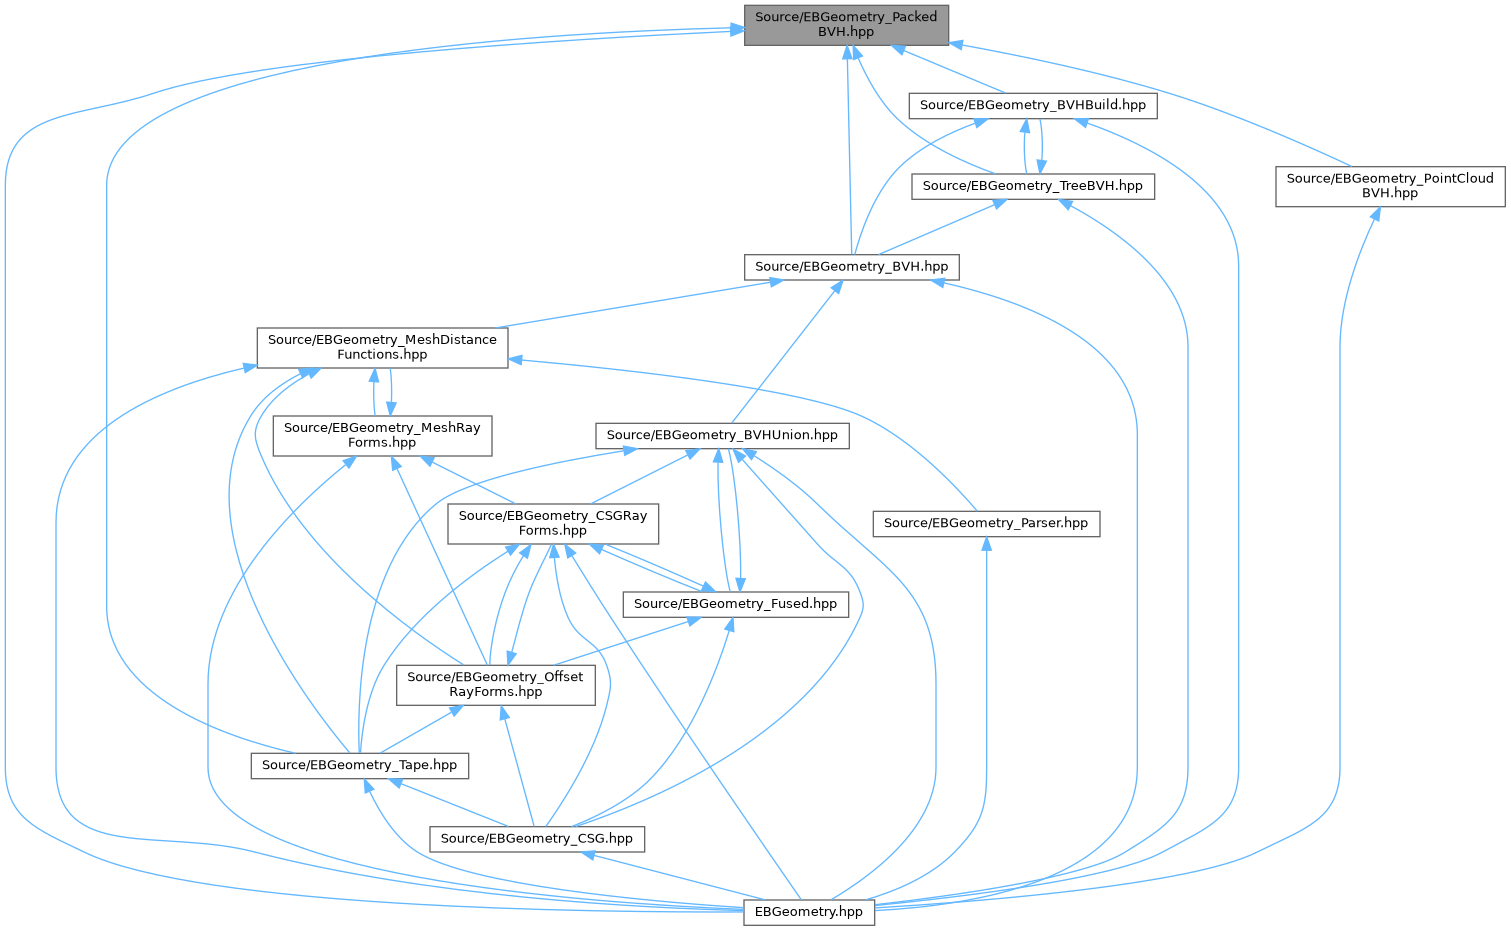
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| struct | EBGeometry::BVH::ClusterSpec |
| Configuration for the ClusterSAH direct PackedBVH construction path. More... | |
| struct | EBGeometry::BVH::ConstructionOptions |
| Leaf-size settings for the preset construction methods, one per family of methods. More... | |
| class | EBGeometry::BVH::PackedBVH< T, P, K > |
| Forward declaration of the linearised BVH, defined below. More... | |
| struct | EBGeometry::BVH::PackedBVH< T, P, K >::Node |
| Compact BVH node stored in the flat node array. More... | |
| struct | EBGeometry::BVH::PackedBVH< T, P, K >::Layout |
| The BVH's arrays as offsets into its pool, and its root box: a PackedBVH minus its location. More... | |
Namespaces | |
| namespace | EBGeometry |
| Namespace containing all of EBGeometry's functionality. | |
| namespace | EBGeometry::SFC |
| Namespace for space-filling curves (SFCs) used to linearly order 3D grid cells. | |
| namespace | EBGeometry::BVH |
| Namespace for various bounding volume hierarchy (BVH) functionalities. | |
Typedefs | |
| template<class P > | |
| using | EBGeometry::BVH::PrimitiveList = std::vector< std::shared_ptr< const P > > |
| Convenience alias for a list of shared primitive pointers. | |
| template<class P , class BV > | |
| using | EBGeometry::BVH::PrimAndBV = std::pair< std::shared_ptr< const P >, BV > |
| Convenience alias for a (primitive, bounding-volume) pair. | |
| template<class P , class BV > | |
| using | EBGeometry::BVH::PrimAndBVList = std::vector< PrimAndBV< P, BV > > |
| Convenience alias for a list of (primitive, bounding-volume) pairs. | |
| template<class P , class BV , size_t K> | |
| using | EBGeometry::BVH::Partitioner = std::function< Array< PrimAndBVList< P, BV >, K >(PrimAndBVList< P, BV > a_primsAndBVs)> |
| Polymorphic partitioner: splits a list of (primitive, BV) pairs into K sub-lists. | |
| template<class T , class P , class BV , size_t K> | |
| using | EBGeometry::BVH::LeafPredicate = std::function< bool(const TreeBVH< T, P, BV, K > &a_node)> |
| Predicate for deciding when a TreeBVH node should become a leaf (i.e., no further splitting). | |
| template<class P > | |
| using | EBGeometry::BVH::LeafEvaluator = std::function< void(const PrimitiveList< P > &a_primitives)> |
| Leaf-evaluation callback for TreeBVH::traverse. | |
| template<class NodeType , class NodeKey > | |
| using | EBGeometry::BVH::PrunePredicate = std::function< bool(const NodeType &a_node, const NodeKey &a_nodeKey)> |
| Node-visit predicate for TreeBVH::traverse(). | |
| template<class NodeType , class NodeKey , size_t K> | |
| using | EBGeometry::BVH::ChildOrderer = std::function< void(Array< std::pair< std::shared_ptr< const NodeType >, NodeKey >, K > &a_children)> |
| Child-ordering callback for TreeBVH traversal. | |
| template<class NodeType , class NodeKey > | |
| using | EBGeometry::BVH::NodeKeyFactory = std::function< NodeKey(const NodeType &a_node)> |
| Node-key factory called once per node during TreeBVH::traverse(). | |
Enumerations | |
| enum class | EBGeometry::BVH::Construction { EBGeometry::BVH::CentroidSplit , EBGeometry::BVH::MidpointSplit , EBGeometry::BVH::SAH , EBGeometry::BVH::ClusterSAH , EBGeometry::BVH::Morton , EBGeometry::BVH::Nested , EBGeometry::BVH::Hilbert } |
| The preset BVH construction methods that the library's own BVH users accept. More... | |
Functions | |
| template<typename T > | |
| constexpr size_t | EBGeometry::BVH::DefaultBranchingRatio () noexcept |
| The default branching factor K: 4, for both float and double, in every translation unit. | |
| template<typename T > | |
| constexpr size_t | EBGeometry::BVH::HostBranchingRatio () noexcept |
| The branching factor K that fills one SIMD register for type T under the compiler's SIMD flags. | |
Variables | |
| constexpr size_t | EBGeometry::BVH::HostTraversalDepth = 256 |
| Deepest tree, in node levels (the root alone is one level), that a host traversal handles. | |
| constexpr size_t | EBGeometry::BVH::DeviceTraversalDepth = 32 |
| Deepest tree, in node levels, that a device traversal handles. | |
Detailed Description
The flattened, device-callable bounding volume hierarchy: PackedBVH, its node layout, traversals and the types shared with the builders.
Device code needs only this header. The host-side builders are TreeBVH and its partitioners (EBGeometry_TreeBVH.hpp), and the PackedBVH constructors that pack a TreeBVH and the static builds that partition a primitive list (EBGeometry_BVHBuild.hpp). Both include this one.
