A PointSoAT<T, W> group that also carries each point's cloud index. More...
#include <EBGeometry_PointAoSoA.hpp>
Public Member Functions | |
| void | pack (const Vec3T< T > *a_positions, const uint32_t *a_pointIds, uint32_t a_count) noexcept |
| Pack a_count (position, point id) pairs into this group. | |
| Array< T, W > | getDistances2 (const Vec3T< T > &a_point) const noexcept |
| Squared unsigned distances from a_point to every one of the W lane points. | |
| Array< T, W > | getDistances (const Vec3T< T > &a_point) const noexcept |
| Unsigned distances from a_point to every one of the W lane points. | |
| T | getMinimumDistance2 (const Vec3T< T > &a_point) const noexcept |
| Shortest squared unsigned distance from a_point to the closest point in this group. | |
| T | getMinimumDistance (const Vec3T< T > &a_point) const noexcept |
| Shortest unsigned distance from a_point to the closest point in this group. | |
| T | getMaximumDistance2 (const Vec3T< T > &a_point) const noexcept |
| Largest squared unsigned distance from a_point to the farthest point in this group. | |
| T | getMaximumDistance (const Vec3T< T > &a_point) const noexcept |
| Largest unsigned distance from a_point to the farthest point in this group. | |
| uint32_t | getPointId (size_t a_lane) const noexcept |
| Get the id of the point in one lane of this group. | |
| uint32_t | numValid () const noexcept |
| Number of real (non-padded) points in this group. | |
| template<class BV > | |
| BV | computeBoundingVolume () const noexcept |
| Compute the bounding volume enclosing all valid points in this group. | |
Protected Attributes | |
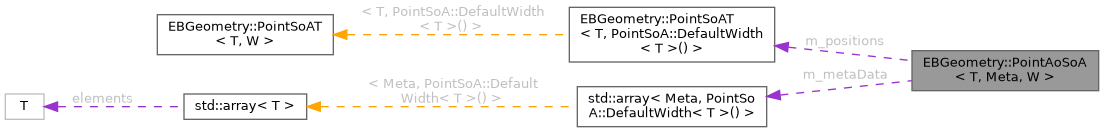
| PointSoAT< T, W > | m_positions |
| The wrapped, position-only SoA block. SIMD-hot: this is all the distance queries ever touch. It also holds the valid-point count. | |
| Array< uint32_t, W > | m_pointIds |
| Per-lane point ids, physically separate from m_positions. m_pointIds[j] = id of point j. Never read by the distance queries. | |
Detailed Description
struct EBGeometry::PointAoSoA< T, W >
A PointSoAT<T, W> group that also carries each point's cloud index.
Structurally this is an AoSoA (Array of Structures of Arrays): PointSoAT<T, W> itself is true SoA (one flat array per coordinate, no per-point structure at all), and PointAoSoA adds exactly one more member – an Array<uint32_t, W> of point ids – alongside it. The two are never merged or interleaved: the distance queries (getMinimumDistance2(), getMaximumDistance2(), getDistances2(), and their sqrt forms – all delegated straight through to the embedded PointSoAT) never read the ids at all, so a pure position-only distance traversal over PointAoSoA-packed leaves touches exactly the same bytes it would touch over bare PointSoAT-packed leaves – an id is only ever read afterward, once a query already knows which lane (and therefore which point) it cares about, via getPointId(). This is the point counterpart of TriangleAoSoA, which carries face ids the same way.
- Template Parameters
-
T Floating-point precision. W SIMD width; see PointSoAT. Defaults to PointSoA::DefaultWidth<T>(), matching PointSoAT's own default.
Member Function Documentation
◆ computeBoundingVolume()
|
noexcept |
Compute the bounding volume enclosing all valid points in this group.
Delegates entirely to the embedded PointSoAT<T, W>.
- Template Parameters
-
BV Bounding volume type (e.g. AABBT<T>); must be constructible from a point array (a Vec3T<T> pointer and a count).
- Returns
- Bounding volume enclosing all valid point positions.
◆ getDistances()
|
noexcept |
Unsigned distances from a_point to every one of the W lane points.
Delegates to PointSoAT<T, W>::getDistances(); the sqrt of each getDistances2() lane.
- Parameters
-
[in] a_point Query point. Must be finite.
- Returns
- Per-lane distances, one per W lanes.
◆ getDistances2()
|
noexcept |
Squared unsigned distances from a_point to every one of the W lane points.
Delegates entirely to the embedded PointSoAT<T, W>; never touches the ids. Padded lanes repeat the last real point's value; see PointSoAT::getDistances2().
- Parameters
-
[in] a_point Query point. Must be finite.
- Returns
- Per-lane squared distances, one per W lanes.
◆ getMaximumDistance()
|
noexcept |
Largest unsigned distance from a_point to the farthest point in this group.
Delegates to PointSoAT<T, W>::getMaximumDistance(); the sqrt of getMaximumDistance2().
- Parameters
-
[in] a_point Query point. Must be finite.
- Returns
- Distance from a_point to the farthest valid point in this group.
◆ getMaximumDistance2()
|
noexcept |
Largest squared unsigned distance from a_point to the farthest point in this group.
Delegates entirely to the embedded PointSoAT<T, W>; never touches the ids.
- Parameters
-
[in] a_point Query point. Must be finite.
- Returns
- Squared distance from a_point to the farthest valid point in this group.
◆ getMinimumDistance()
|
noexcept |
Shortest unsigned distance from a_point to the closest point in this group.
Delegates to PointSoAT<T, W>::getMinimumDistance(); the sqrt of getMinimumDistance2().
- Parameters
-
[in] a_point Query point. Must be finite.
- Returns
- Distance from a_point to the closest valid point in this group.
◆ getMinimumDistance2()
|
noexcept |
Shortest squared unsigned distance from a_point to the closest point in this group.
Delegates entirely to the embedded PointSoAT<T, W>; never touches the ids. Avoids the sqrt that getMinimumDistance() pays – prefer it whenever the caller only needs the distance for comparison, not its actual magnitude.
- Parameters
-
[in] a_point Query point. Must be finite.
- Returns
- Squared distance from a_point to the closest valid point in this group.
◆ getPointId()
|
noexcept |
◆ numValid()
|
inlinenoexcept |
◆ pack()
|
noexcept |
Pack a_count (position, point id) pairs into this group.
Pads lanes a_count..W-1 by repeating the last real position and id, matching PointSoAT::pack()'s own padding convention, so all W lanes hold valid data. Scans that must see each point once stop at numValid().
- Parameters
-
[in] a_positions Source position array with at least a_count elements. Must not be null. [in] a_pointIds Source id array (typically cloud indices) with at least a_count elements, same order and length as a_positions. Must not be null. [in] a_count Number of valid (position, id) pairs to pack. Must satisfy 1 <= a_count <= W.
The documentation for this struct was generated from the following file:
- Source/EBGeometry_PointAoSoA.hpp
