Query results and helpers shared by the point-cloud search structures. More...
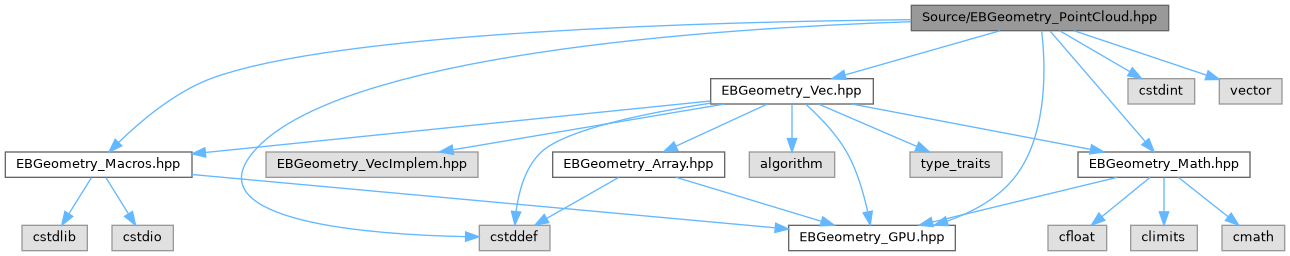
#include <cstddef>#include <cstdint>#include <vector>#include "EBGeometry_GPU.hpp"#include "EBGeometry_Macros.hpp"#include "EBGeometry_Math.hpp"#include "EBGeometry_Vec.hpp"
Include dependency graph for EBGeometry_PointCloud.hpp:
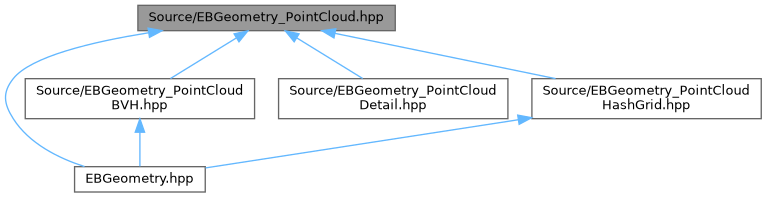
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| struct | EBGeometry::PointCloud::Hit< T > |
| One query result: the cloud index of a matched point and its squared distance. More... | |
| class | EBGeometry::PointCloud::KBest< T > |
| The k nearest points seen so far, kept sorted in a caller-supplied buffer. More... | |
Namespaces | |
| namespace | EBGeometry |
| Namespace containing all of EBGeometry's functionality. | |
| namespace | EBGeometry::PointCloud |
| Query results and helpers shared by PointCloudBVH and PointCloudHashGrid. | |
Functions | |
| template<class T > | |
| std::size_t | EBGeometry::PointCloud::closestPointsBruteForce (const Vec3T< T > *a_positions, const uint32_t a_numPoints, const Vec3T< T > &a_query, const std::size_t a_k, Hit< T > *a_out, const uint32_t a_exclude=InvalidIndex) noexcept |
| The a_k points of a cloud nearest to a query point, by a full scan. | |
| template<class T > | |
| Hit< T > | EBGeometry::PointCloud::closestPointBruteForce (const Vec3T< T > *a_positions, const uint32_t a_numPoints, const Vec3T< T > &a_query, const uint32_t a_exclude=InvalidIndex) noexcept |
| The point of a cloud nearest to a query point, by a full scan. | |
Variables | |
| constexpr uint32_t | EBGeometry::PointCloud::InvalidIndex = Math::Limits<uint32_t>::max() |
| The cloud index of "no point": a miss, or a result slot a query could not fill. | |
Detailed Description
Query results and helpers shared by the point-cloud search structures.
