A BVH over spheres of differing radii, built where its pool is: the signed distance to their union and the closest sphere. More...
#include <cmath>#include <cstddef>#include <cstdint>#include <type_traits>#include <vector>#include "EBGeometry_BoundingVolumes.hpp"#include "EBGeometry_CloudBVH.hpp"#include "EBGeometry_GPUAlgorithms.hpp"#include "EBGeometry_PackedBVH.hpp"#include "EBGeometry_Pool.hpp"#include "EBGeometry_SphereAoSoA.hpp"#include "EBGeometry_SphereCloud.hpp"#include "EBGeometry_Vec.hpp"#include "EBGeometry_SphereCloudBVHImplem.hpp"
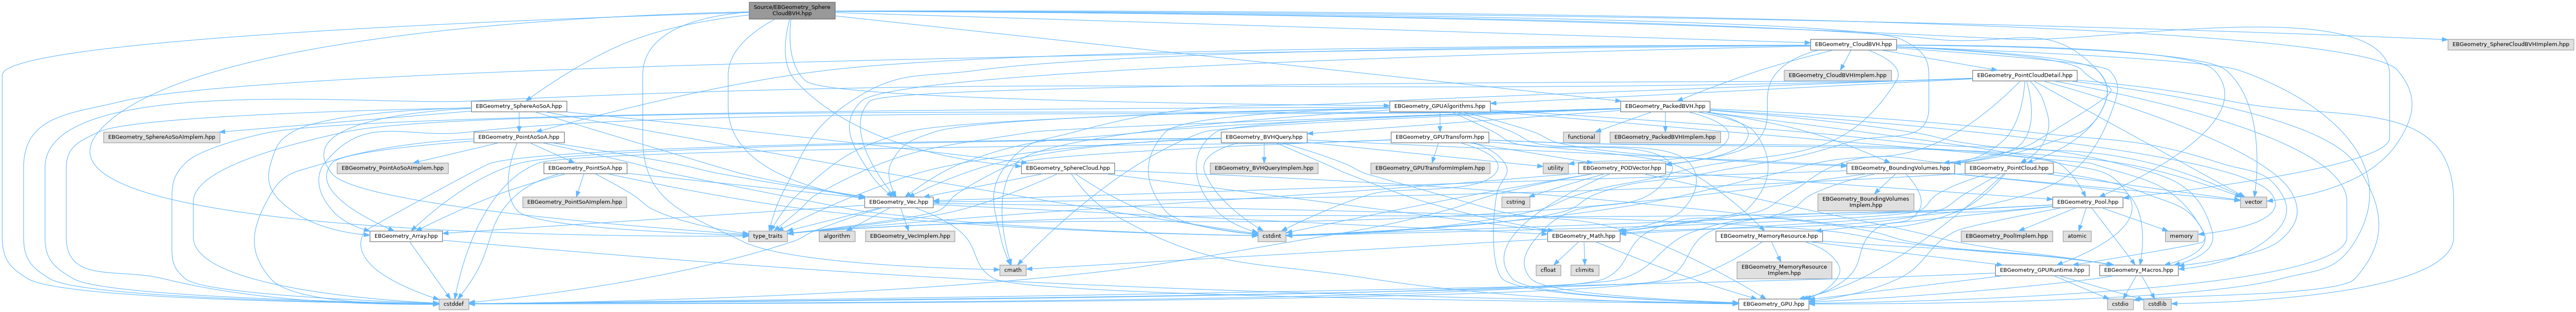
Include dependency graph for EBGeometry_SphereCloudBVH.hpp:
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| struct | EBGeometry::PointCloudDetail::RadiiAsPoints< T, Source > |
| A source of points that are a sphere's radius in every coordinate: GPU::boundingBoxOf() over it finds the smallest radius and whether every radius is finite. More... | |
| struct | EBGeometry::PointCloudDetail::SpherePrimitive< T, W > |
| The primitive of SphereCloudBVH: a sphere, keyed at its center and packed into SphereAoSoA groups; see PointPrimitive. More... | |
| class | EBGeometry::SphereCloudBVH< T, K, W > |
| A BVH over spheres of differing radii (polydisperse particles), with the signed distance to their union, the closest sphere, and the contacts between spheres. More... | |
Namespaces | |
| namespace | EBGeometry |
| Namespace containing all of EBGeometry's functionality. | |
| namespace | EBGeometry::PointCloudDetail |
| Internal helpers shared by the point-cloud search structures; not part of the public API. | |
Detailed Description
A BVH over spheres of differing radii, built where its pool is: the signed distance to their union and the closest sphere.
