Internal helpers shared by PointCloudBVH and PointCloudHashGrid, and by their builds. More...
#include <cmath>#include <cstddef>#include <cstdint>#include <cstdio>#include <cstdlib>#include <vector>#include "EBGeometry_BoundingVolumes.hpp"#include "EBGeometry_GPU.hpp"#include "EBGeometry_GPUAlgorithms.hpp"#include "EBGeometry_Macros.hpp"#include "EBGeometry_Math.hpp"#include "EBGeometry_PointCloud.hpp"#include "EBGeometry_Vec.hpp"
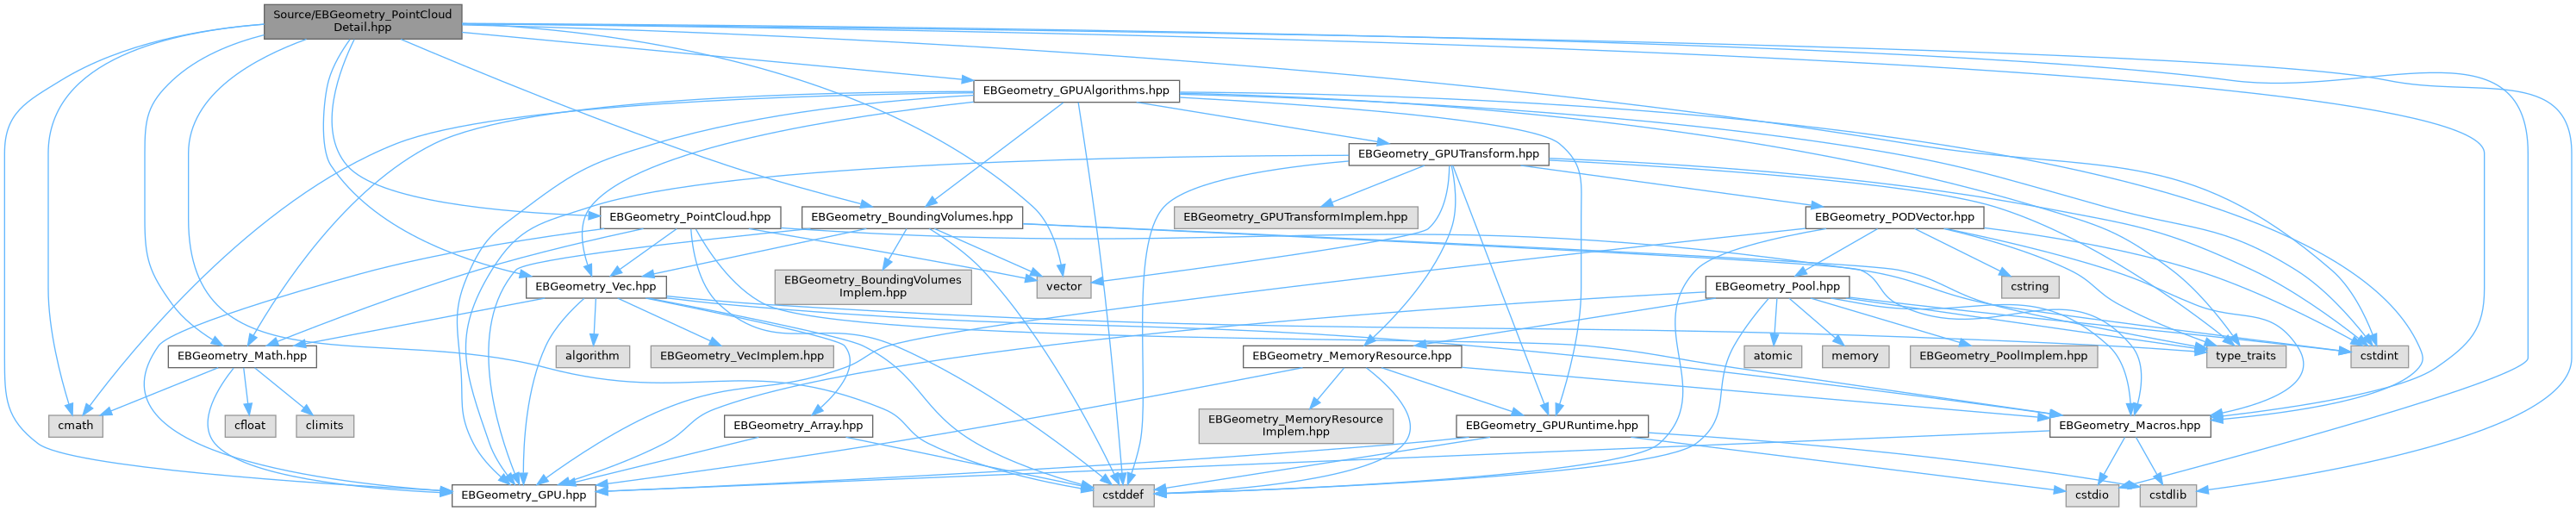
Include dependency graph for EBGeometry_PointCloudDetail.hpp:
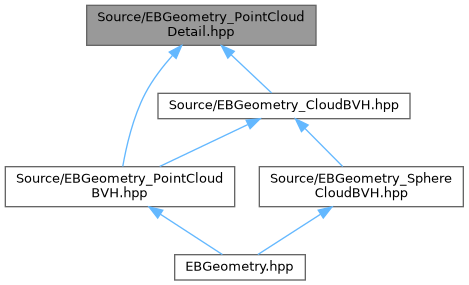
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Namespaces | |
| namespace | EBGeometry |
| Namespace containing all of EBGeometry's functionality. | |
| namespace | EBGeometry::PointCloudDetail |
| Internal helpers shared by the point-cloud search structures; not part of the public API. | |
Functions | |
| template<class T > | |
| void | EBGeometry::PointCloudDetail::requireValidCloud (const char *a_who, const std::vector< Vec3T< T > > &a_positions) noexcept |
| Abort with a message unless a point cloud can be indexed. | |
| uint32_t | EBGeometry::PointCloudDetail::keyCount (const uint32_t a_n) noexcept |
The smallest power of two at least a_n, and 0 for 0: how many keys a build sorts with GPU::bitonicSort(). | |
| template<class T , class Source > | |
| BoundingVolumes::AABBT< T > | EBGeometry::PointCloudDetail::boxOf (const Source &a_source, const uint32_t a_numPoints, const bool a_parallel, Vec3T< T > *a_scratch, const char *a_who, const char *a_noun="point") |
| The box of a cloud, found where a build runs, and every coordinate checked finite. | |
Detailed Description
Internal helpers shared by PointCloudBVH and PointCloudHashGrid, and by their builds.
