Declaration of Affine3T, an affine map of 3D space (a 3x3 matrix and a shift). More...
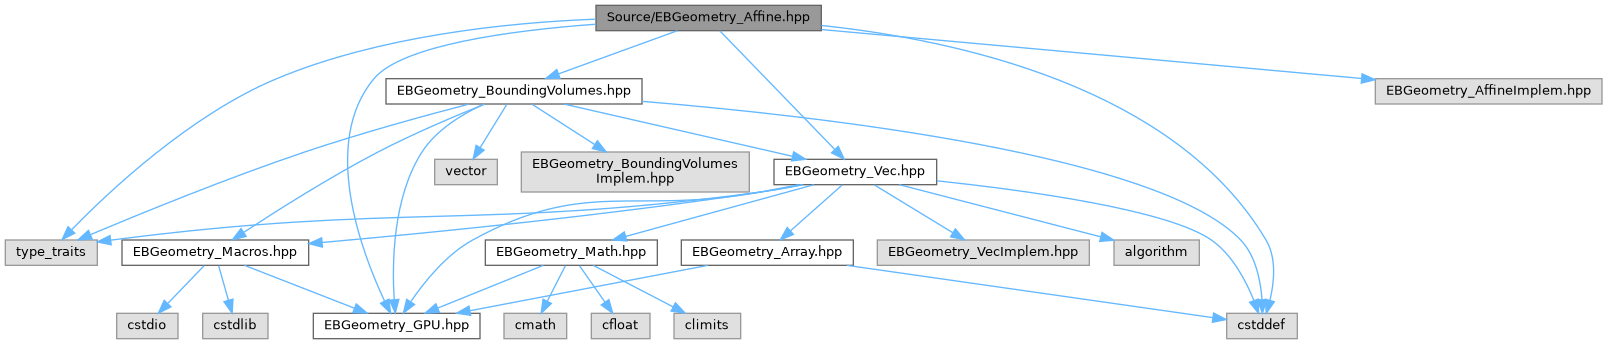
#include <cstddef>#include <type_traits>#include "EBGeometry_BoundingVolumes.hpp"#include "EBGeometry_GPU.hpp"#include "EBGeometry_Vec.hpp"#include "EBGeometry_AffineImplem.hpp"
Include dependency graph for EBGeometry_Affine.hpp:
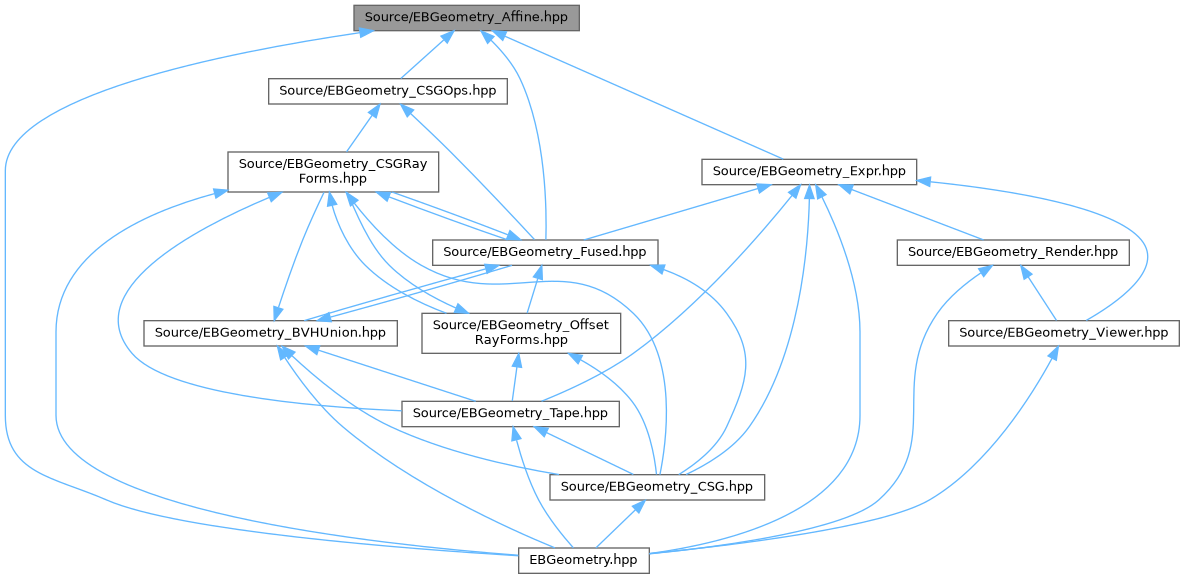
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| struct | EBGeometry::Affine3T< T > |
| An affine map of 3D space, x -> A x + b, with A stored by rows. More... | |
Namespaces | |
| namespace | EBGeometry |
| Namespace containing all of EBGeometry's functionality. | |
Detailed Description
Declaration of Affine3T, an affine map of 3D space (a 3x3 matrix and a shift).
The expression builder and the fused operations fold every chain of Translate, Rotate, Reflect and Scale into one Affine3T, which the Tape or the fused node applies to the query point before evaluating the transformed subtree. Device-callable.
